GEAR DexUMI

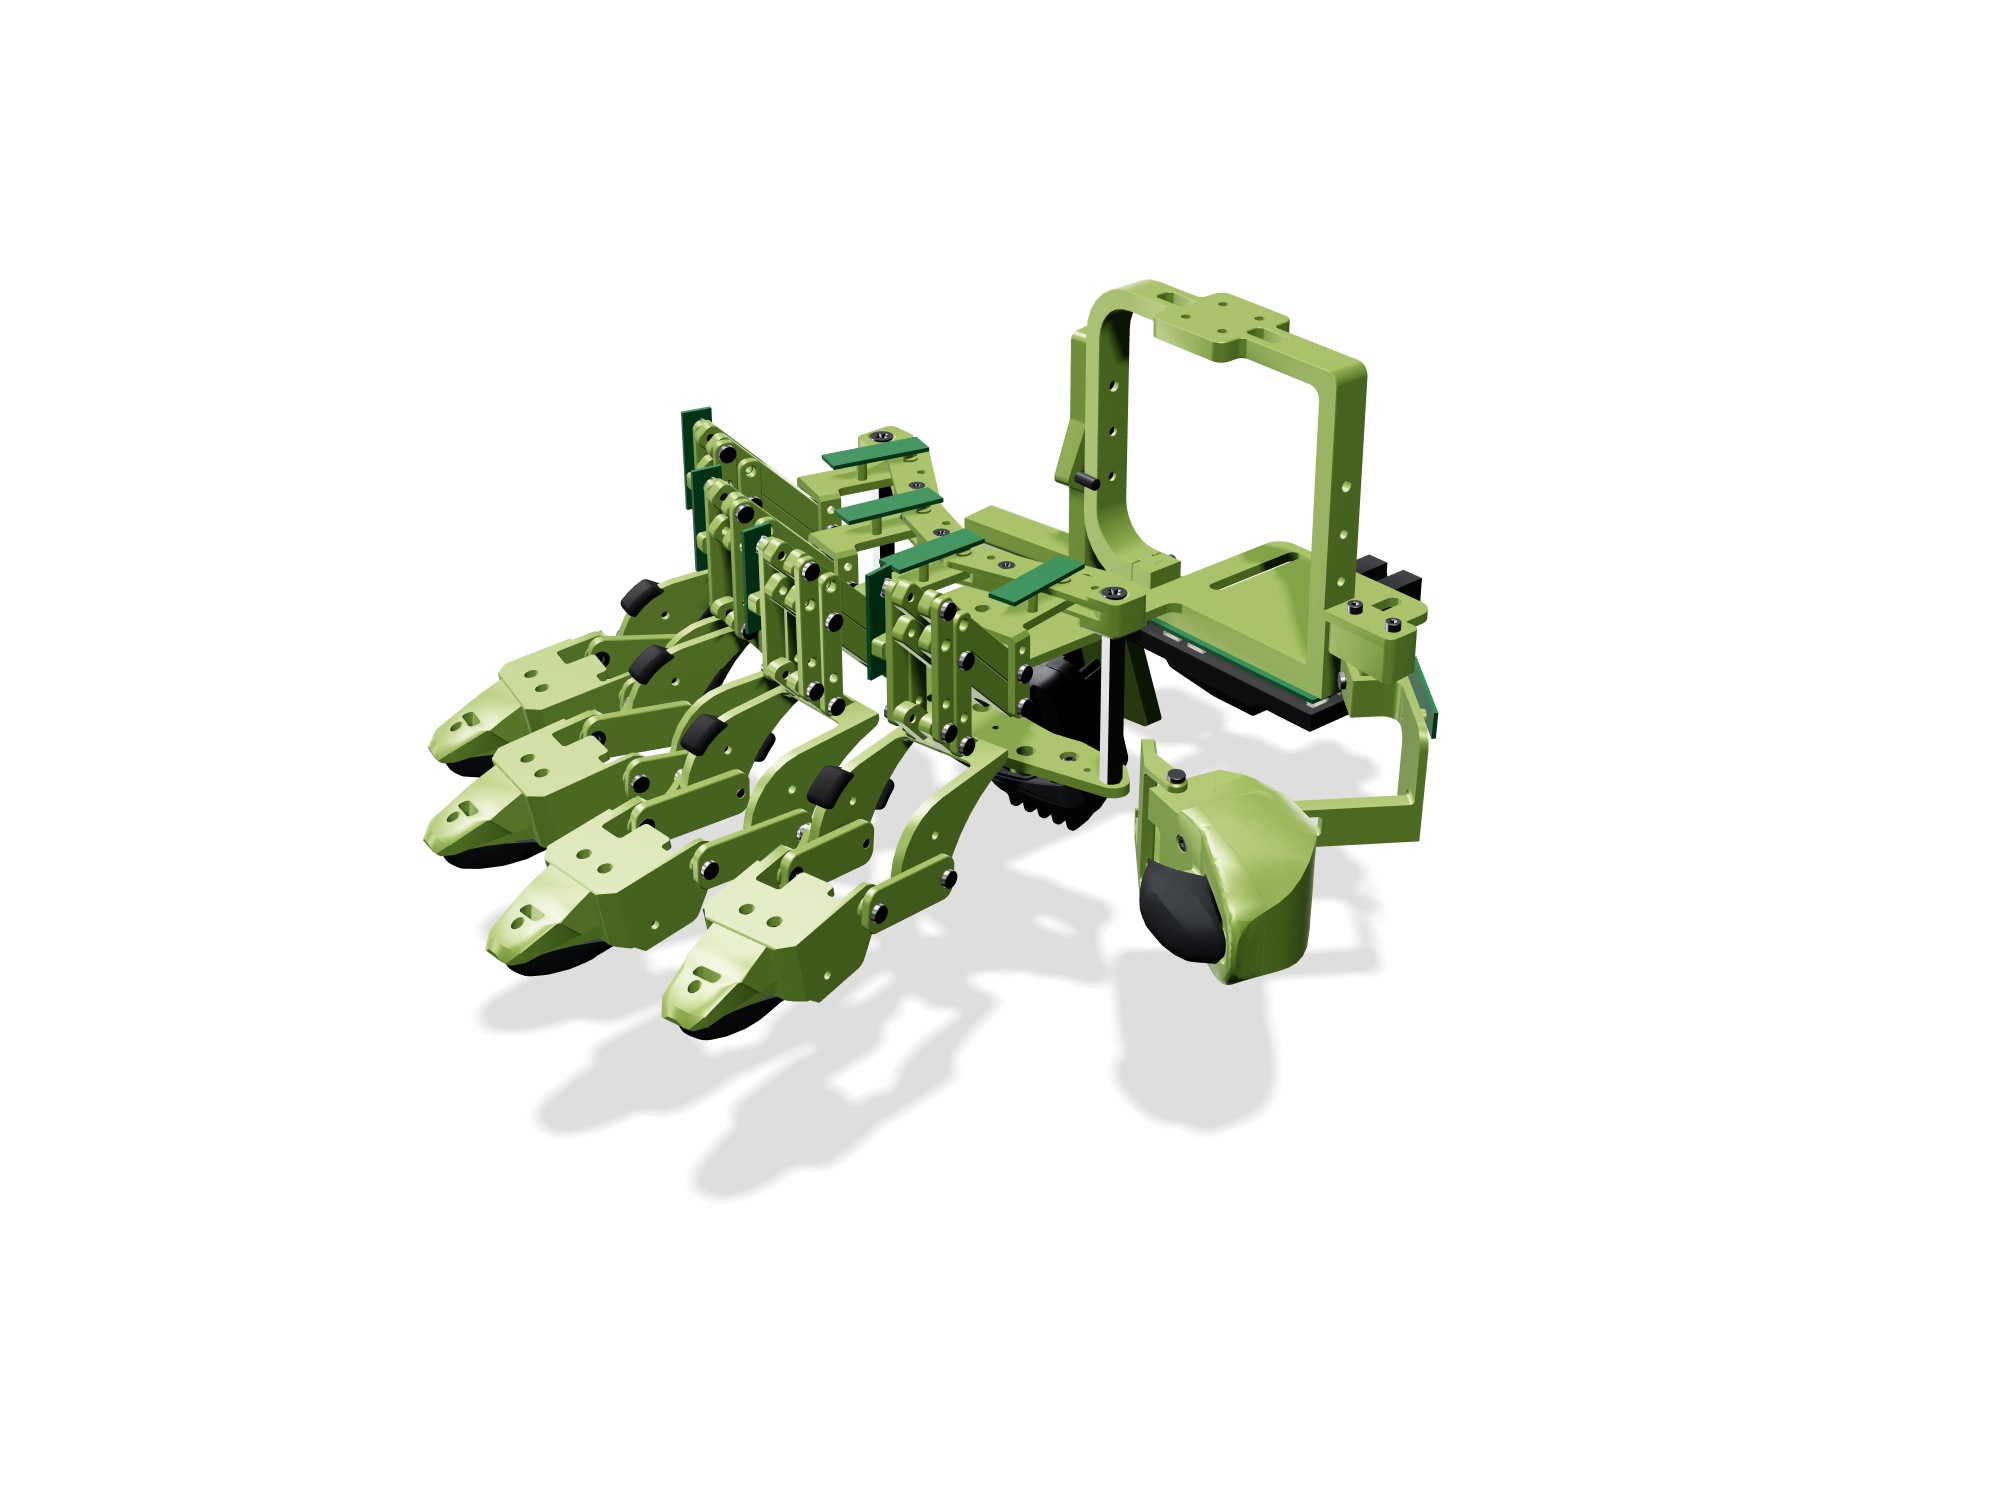
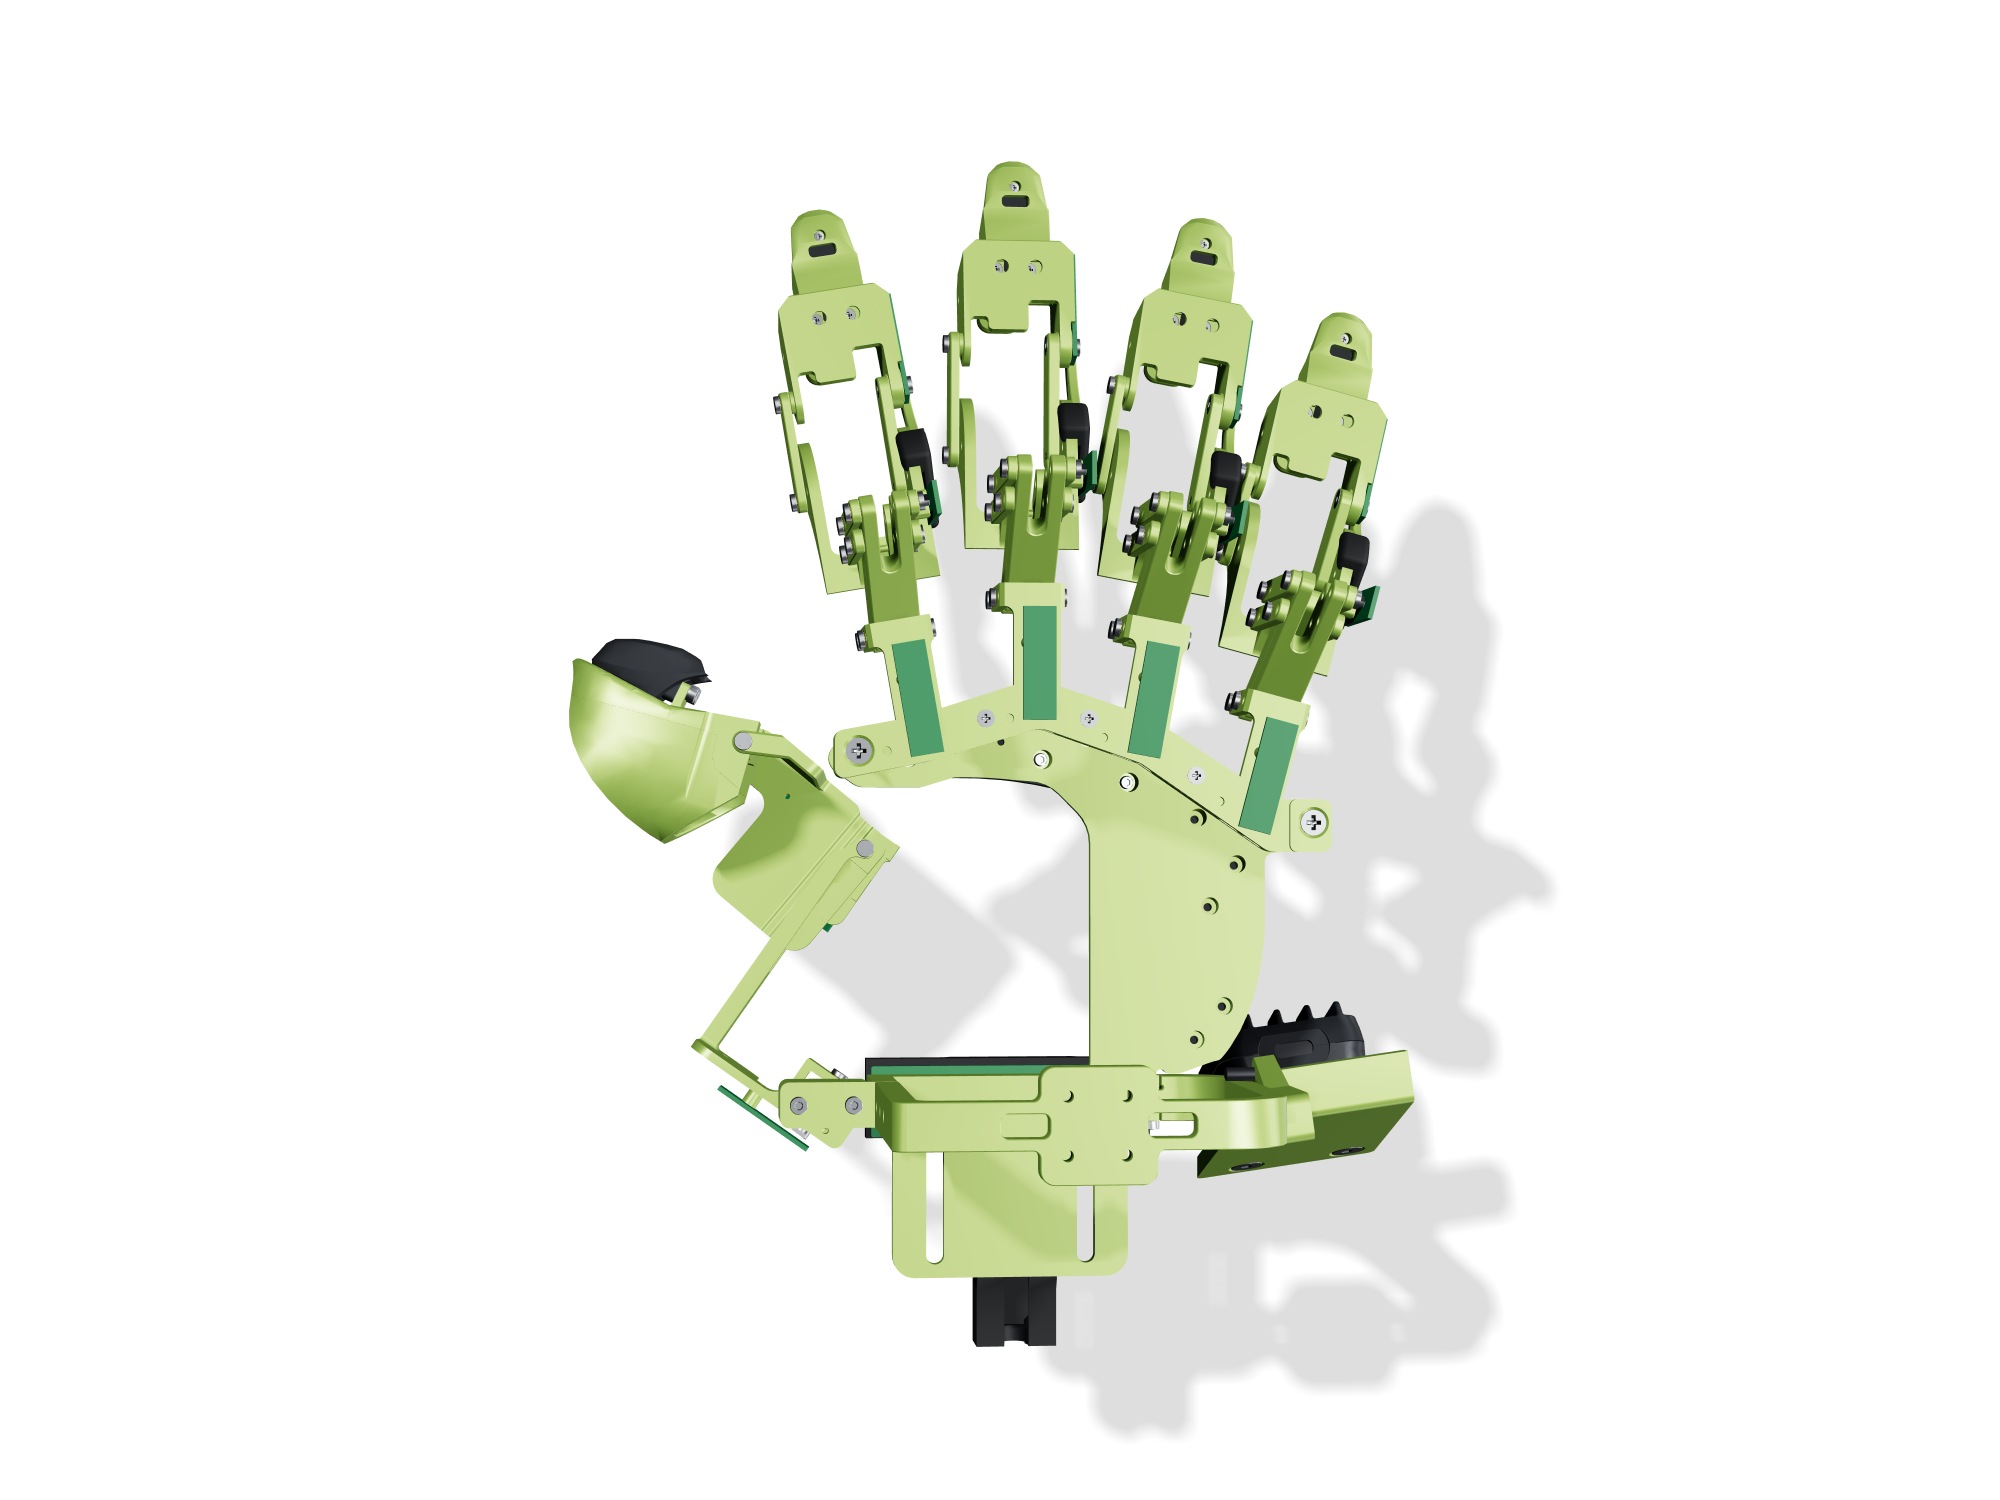
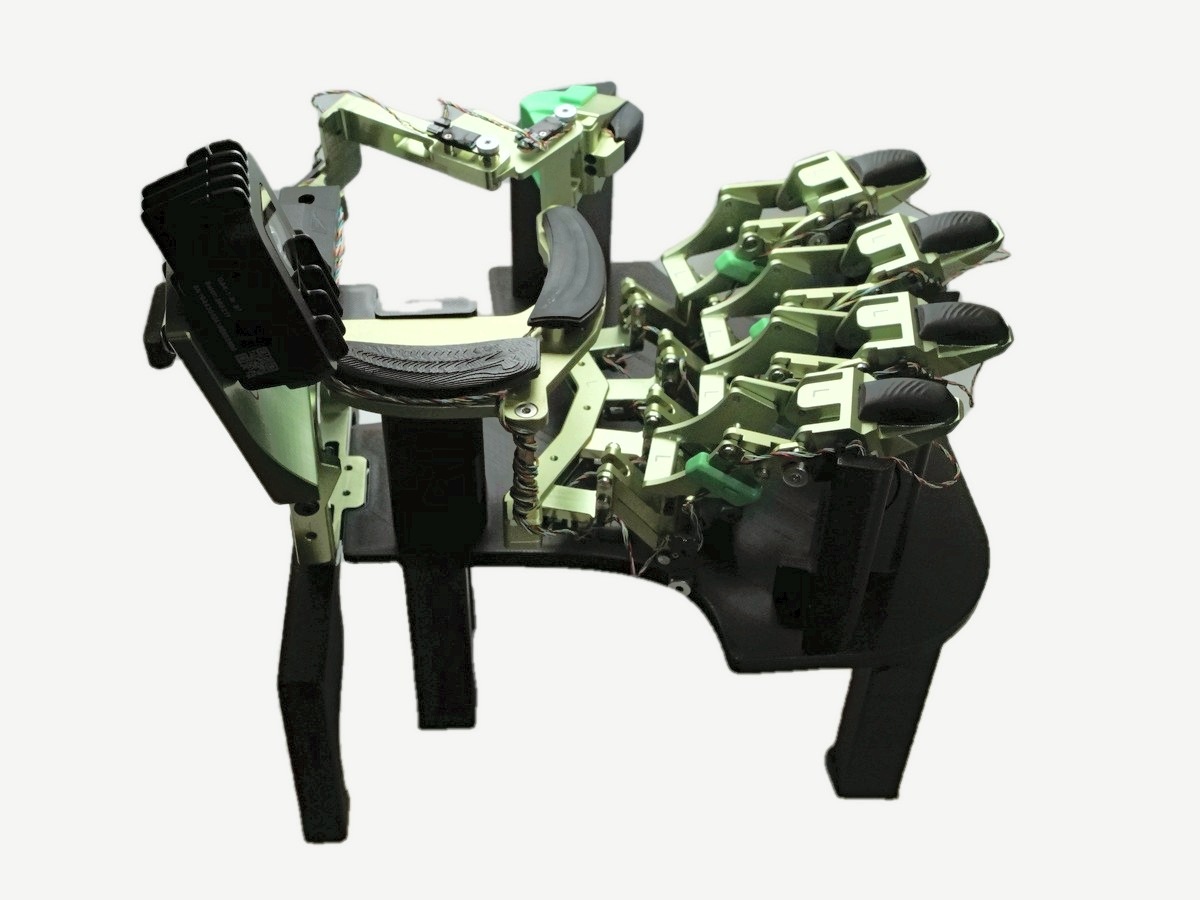
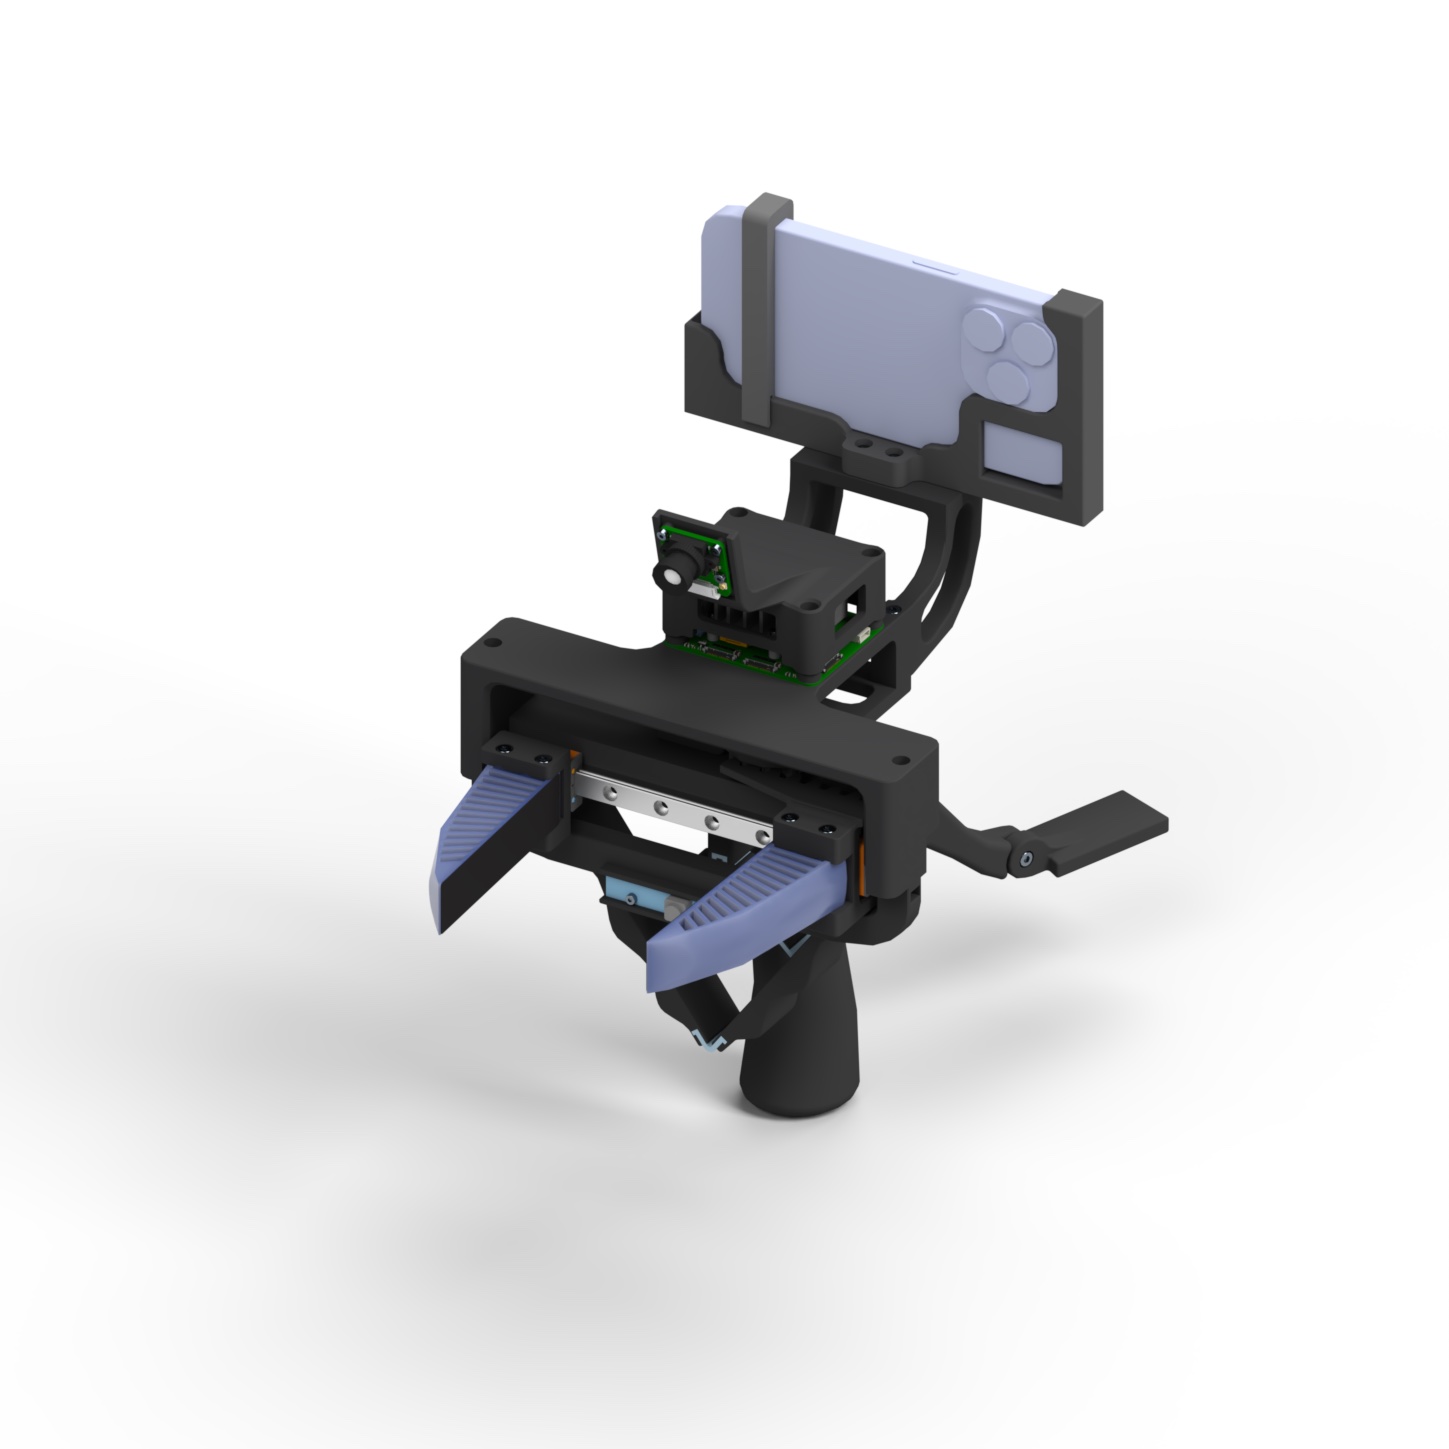
These hardware prototypes were developed by the NVIDIA GEAR team to collect high-quality training data for general robot foundation models. We fully tested the designs by collecting data for GR00T 2, our foundation world-action model for robot manipulation.
We are releasing them as open-source designs so others can build the same hardware and collect data the same way. Each project includes a bill of materials, mechanical and electrical design files, a step-by-step assembly guide and a software guide.
Higher DoF and better wearability than the original DexUMI exoskeleton, for collecting dexterous post-training data.
Open DexUMI documentation16 DoF per hand 5 fingertip tactile sensors per hand

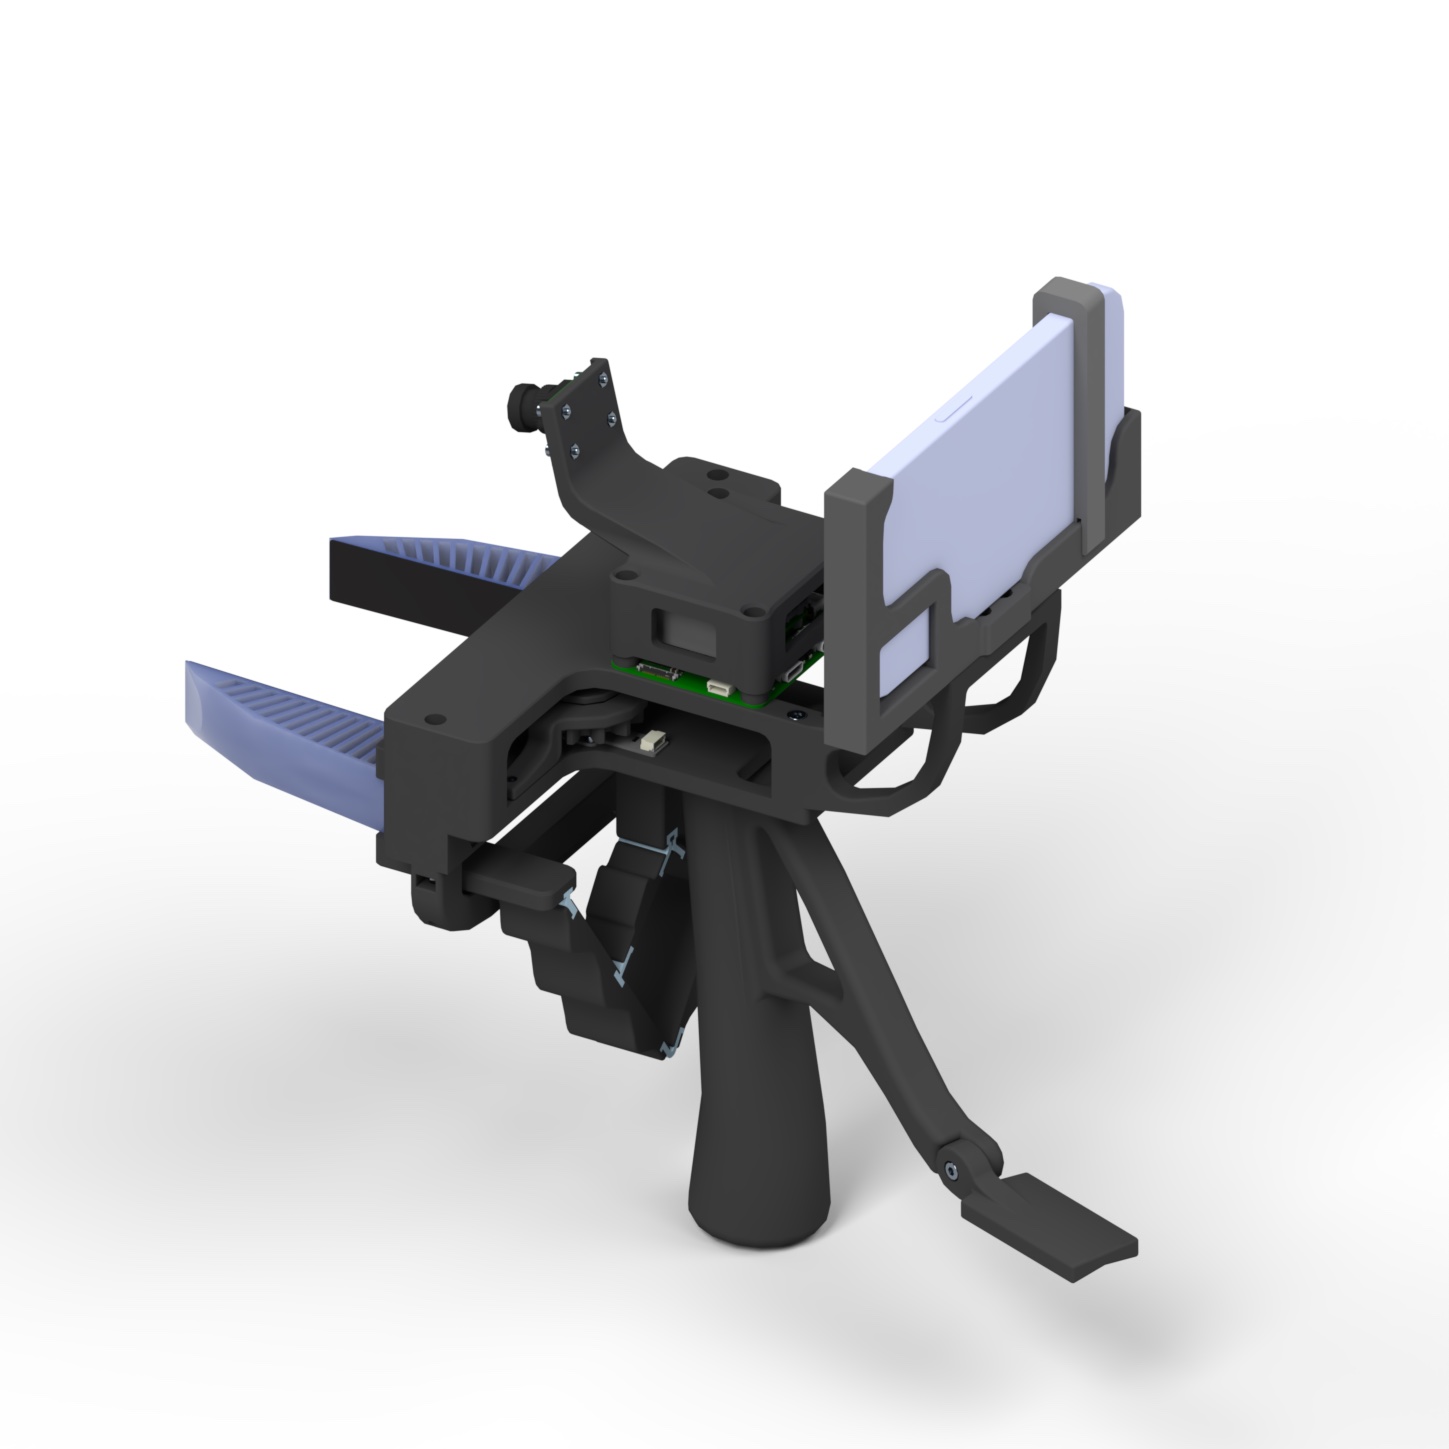
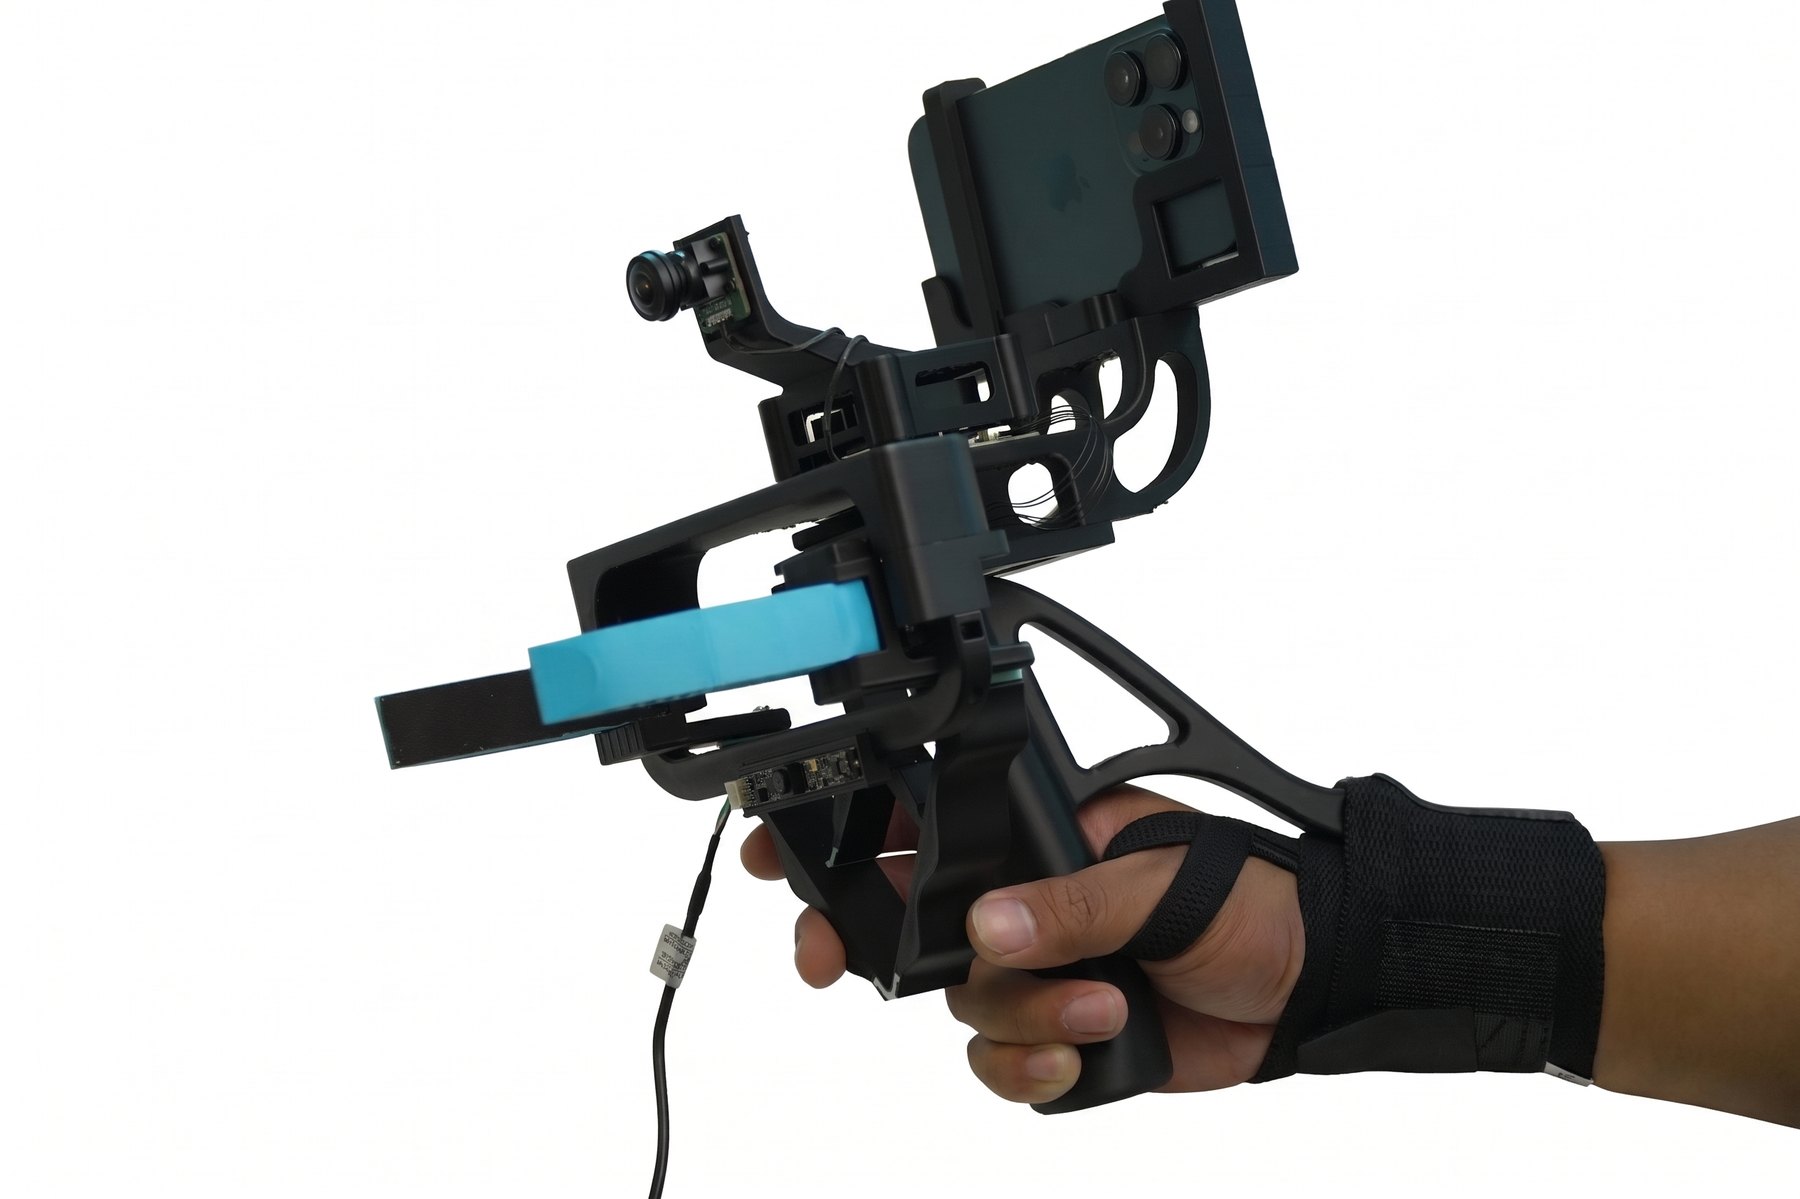

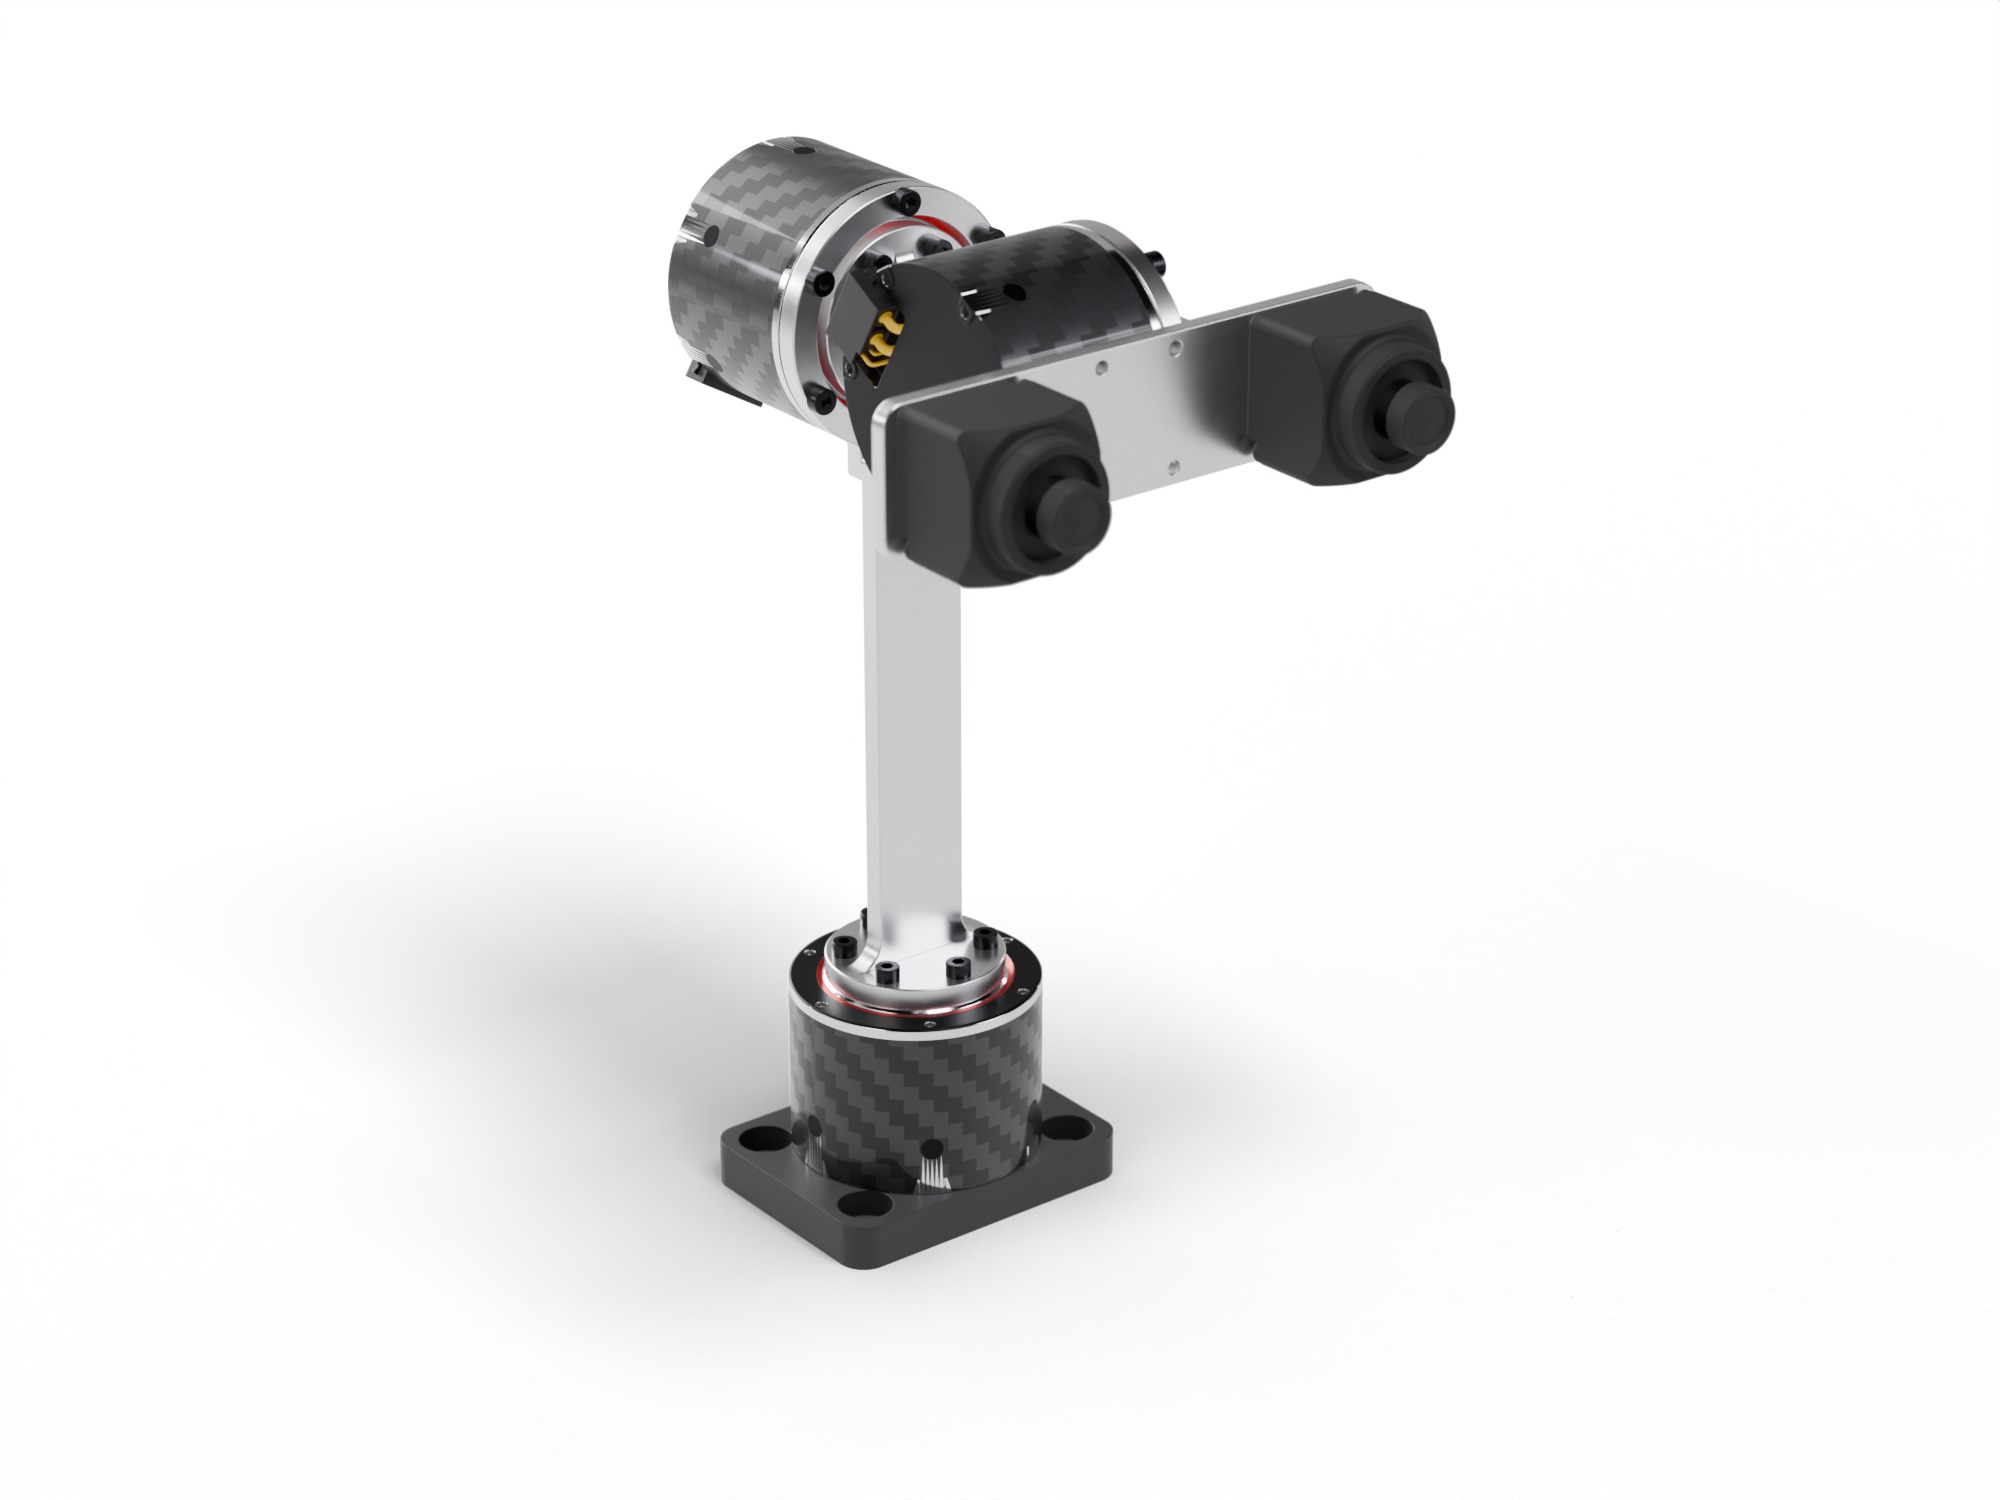
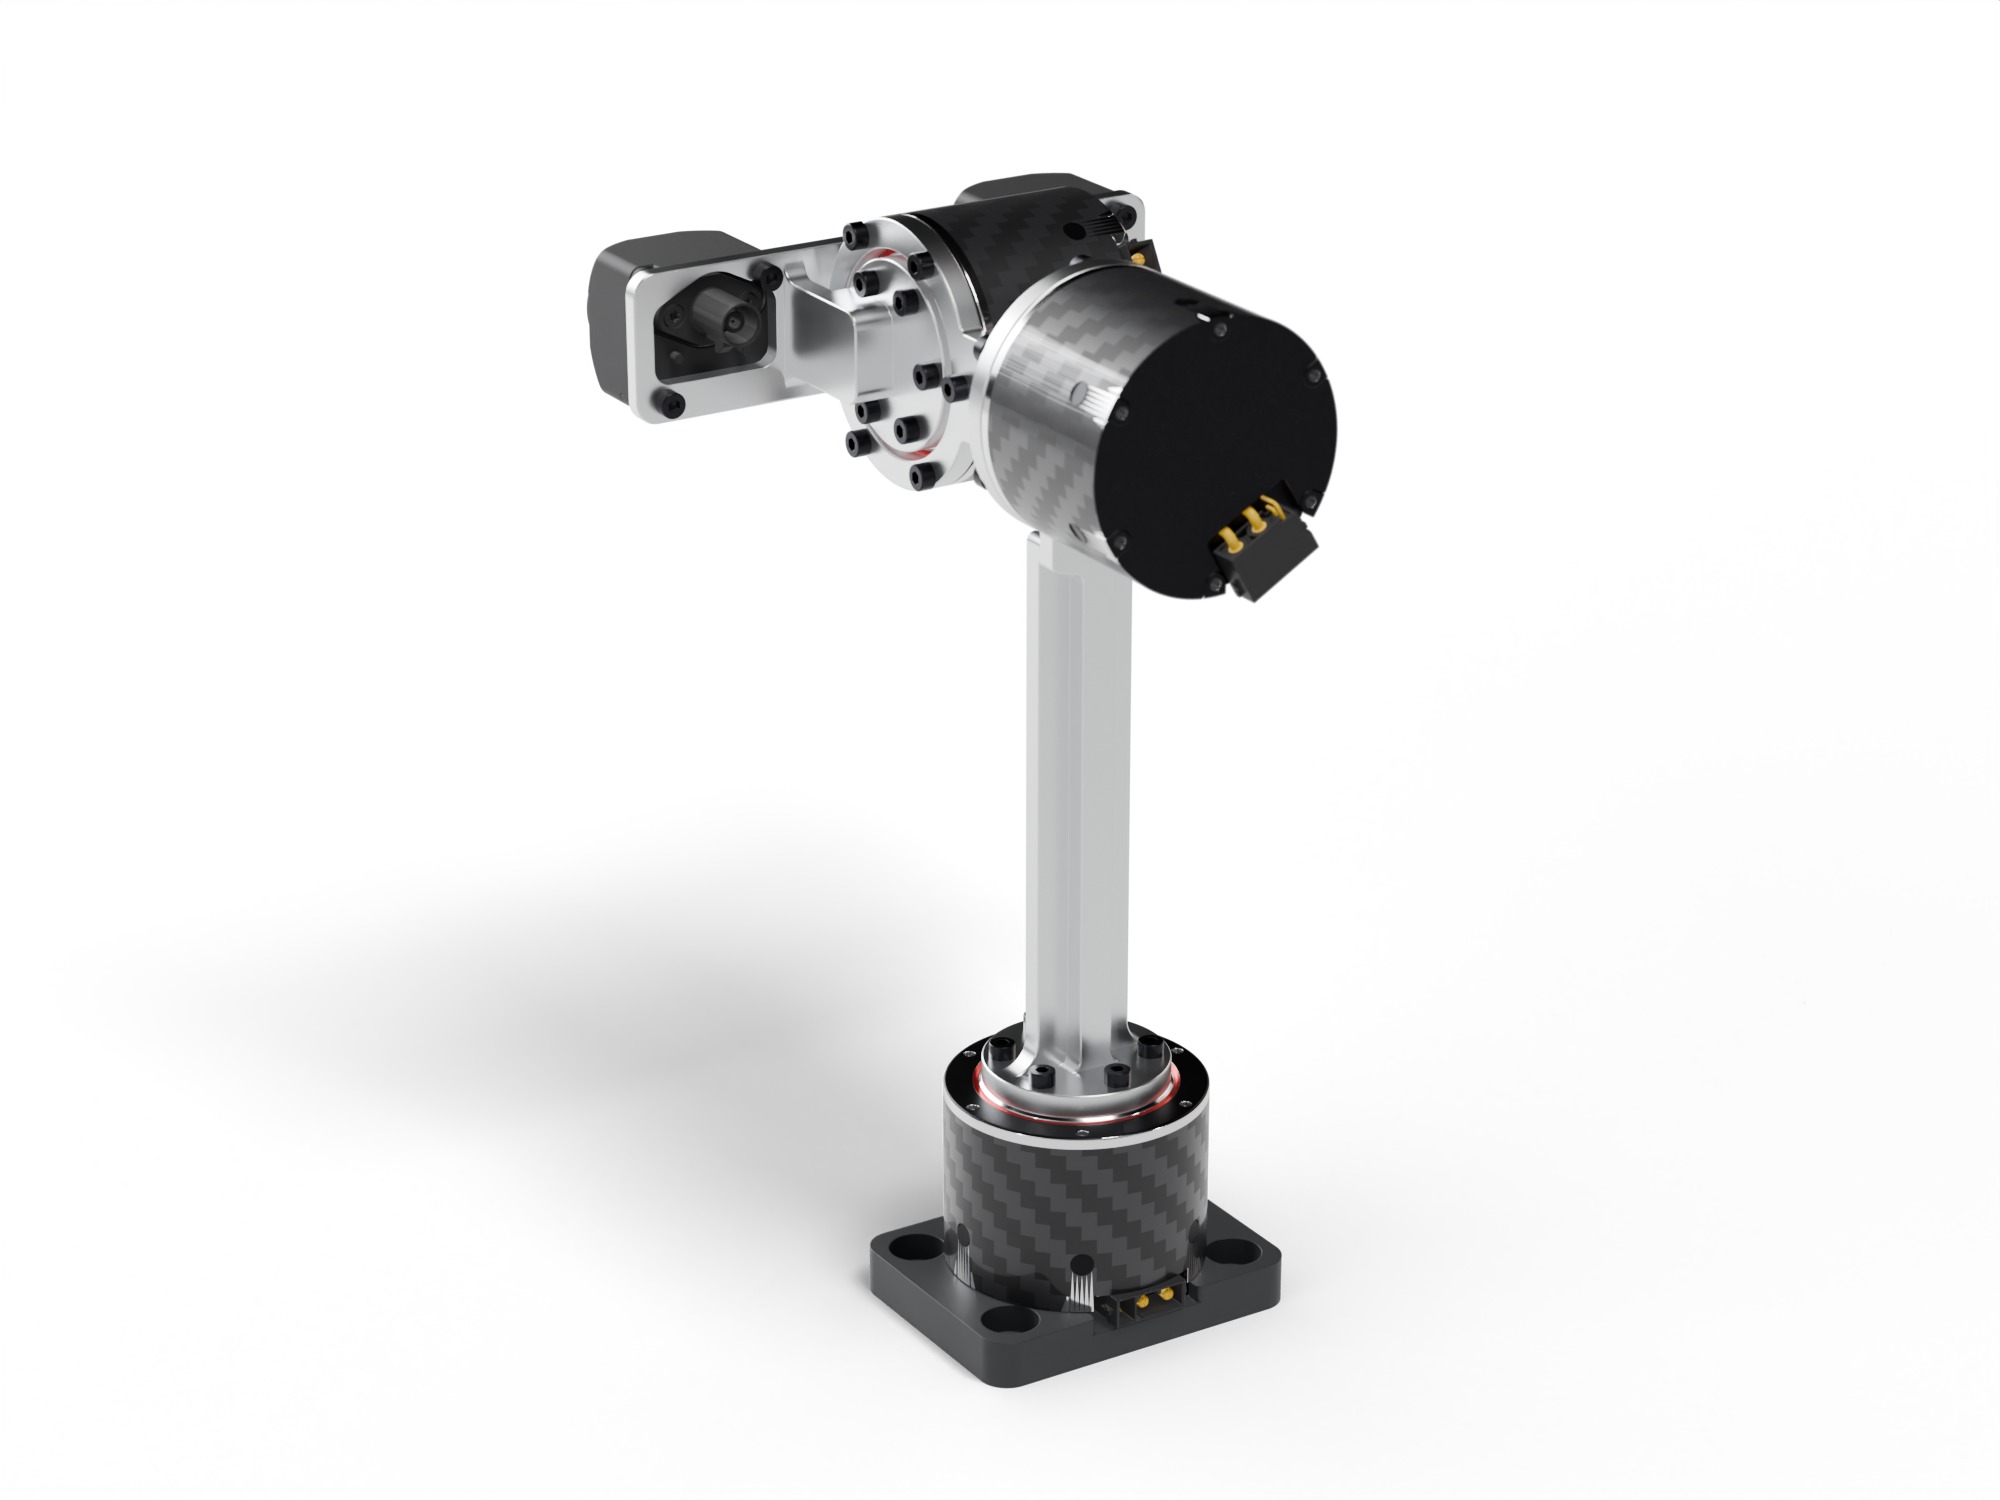

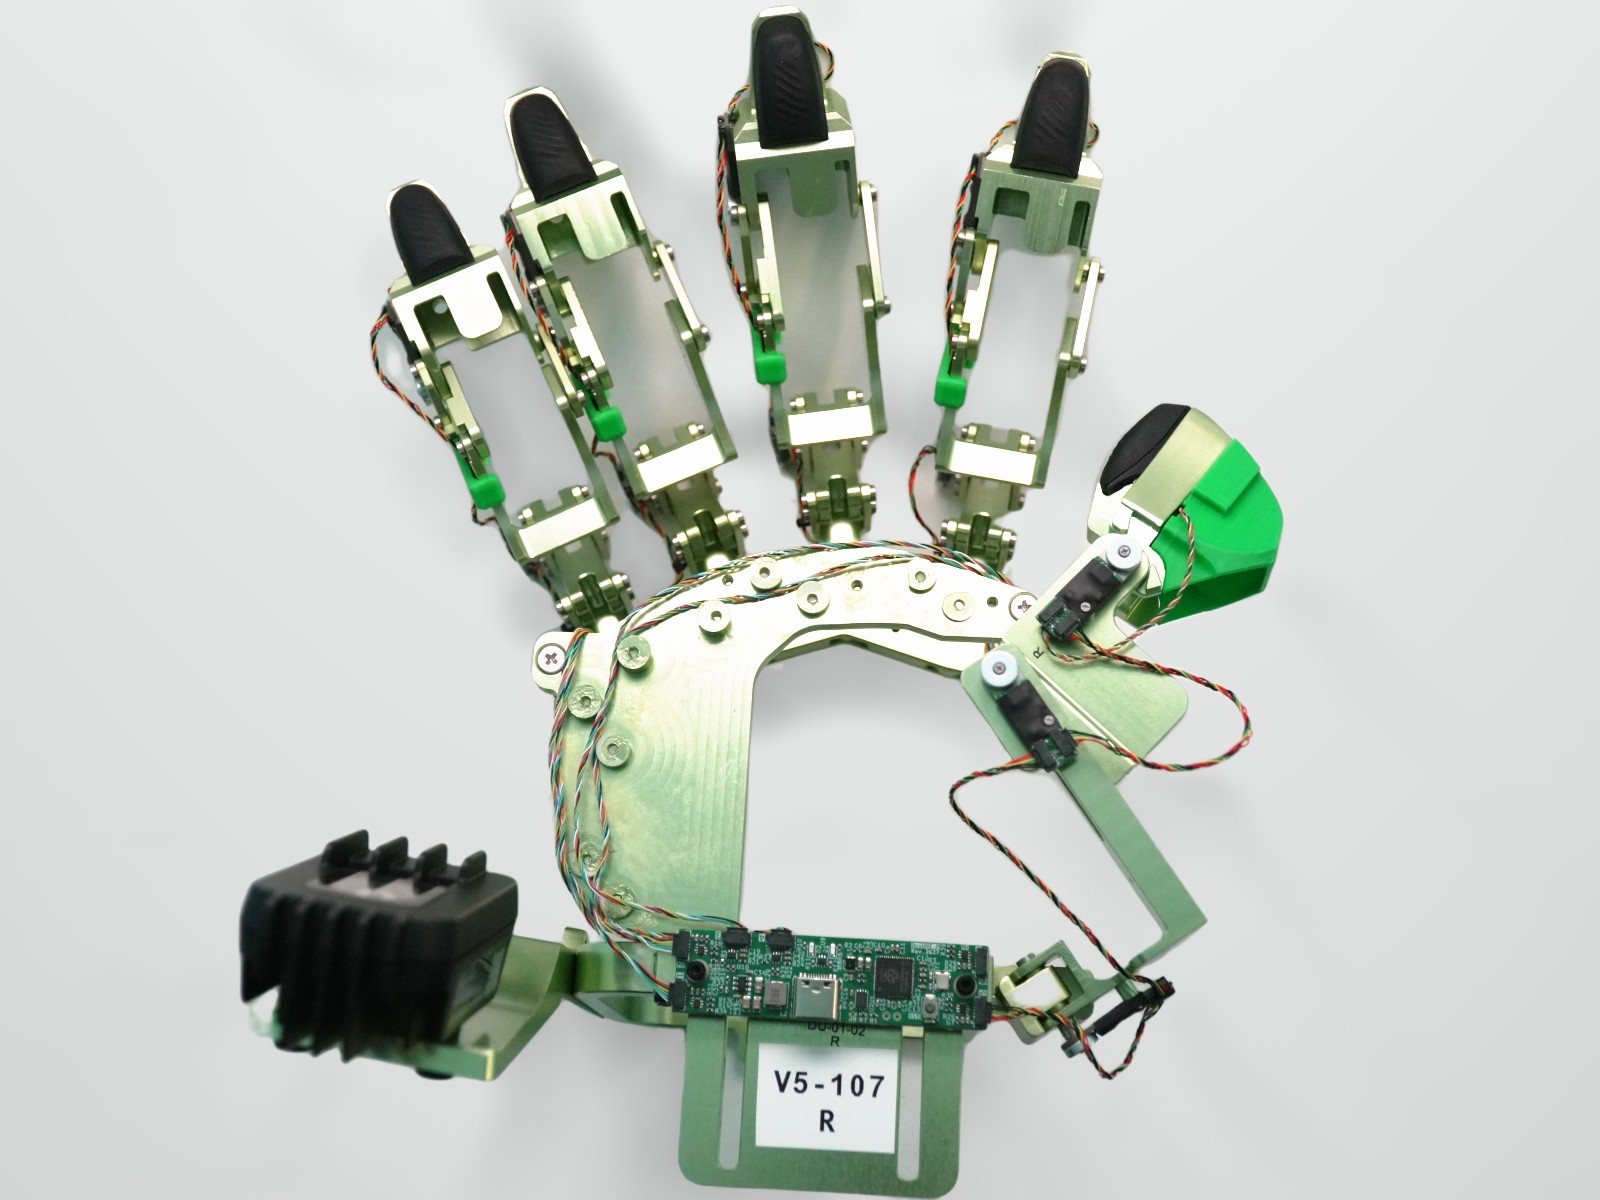
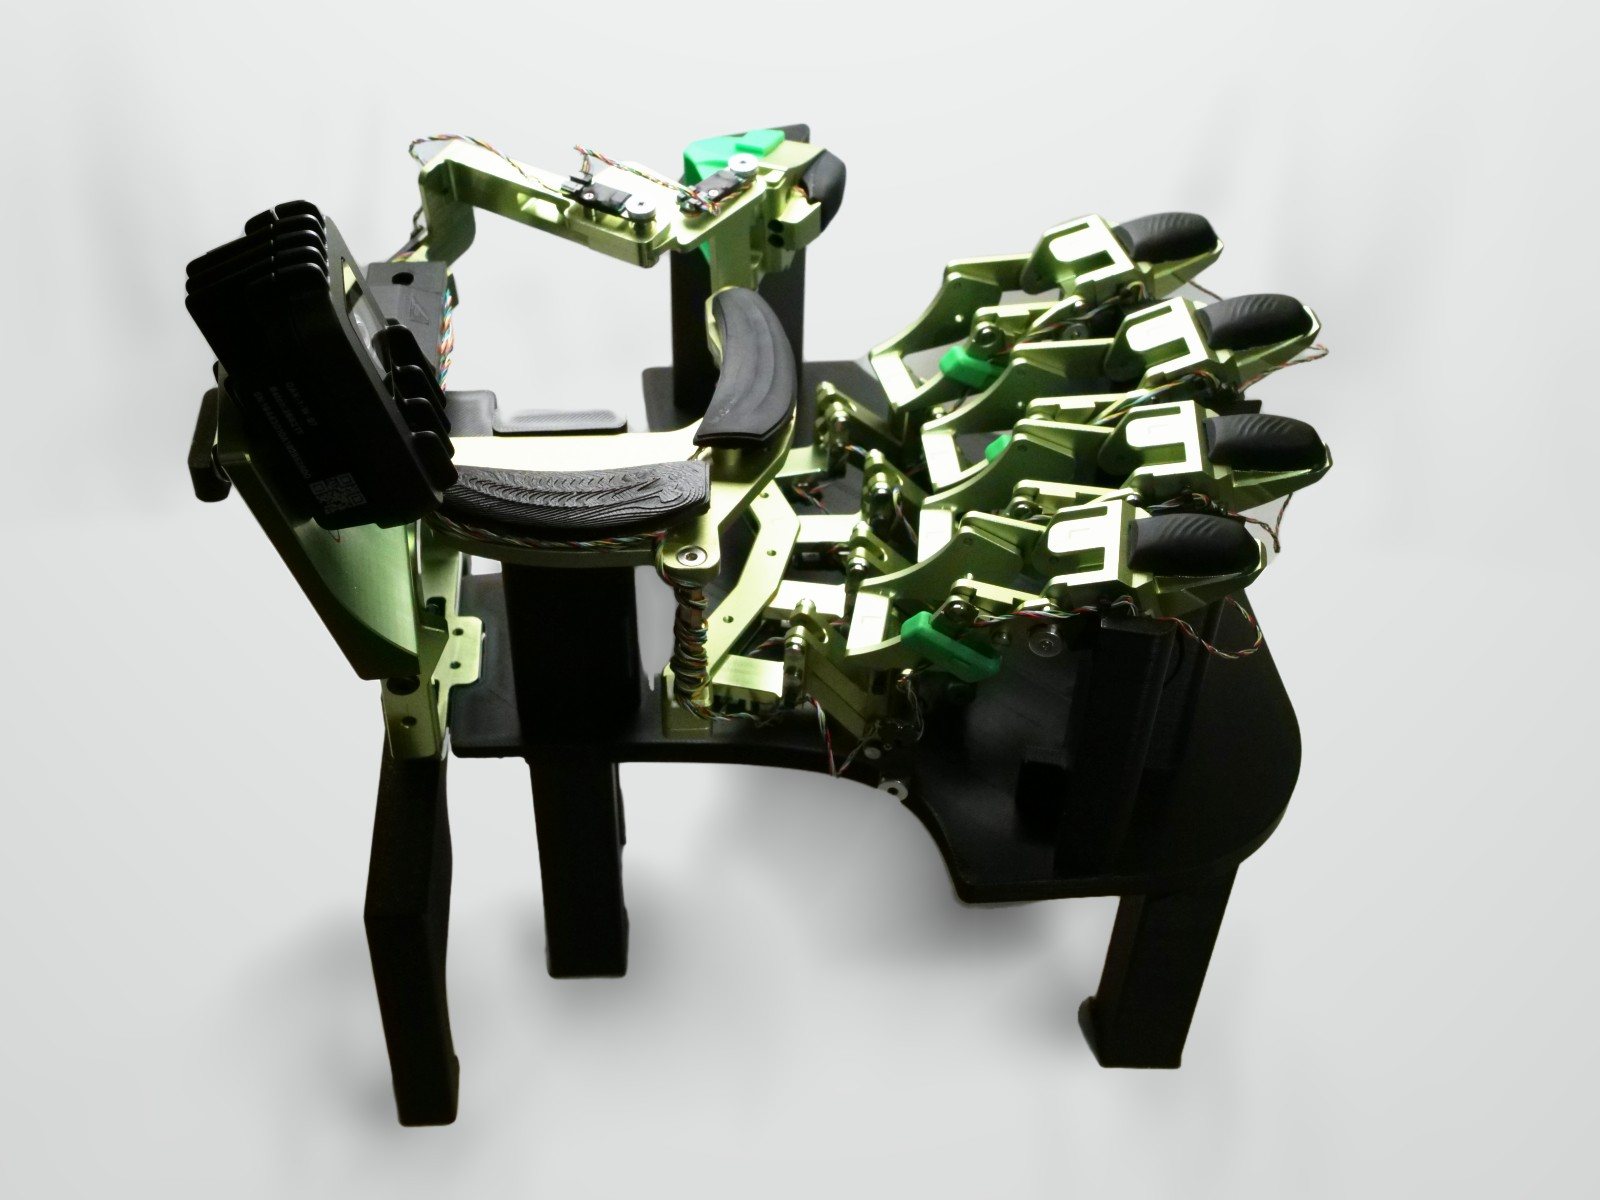
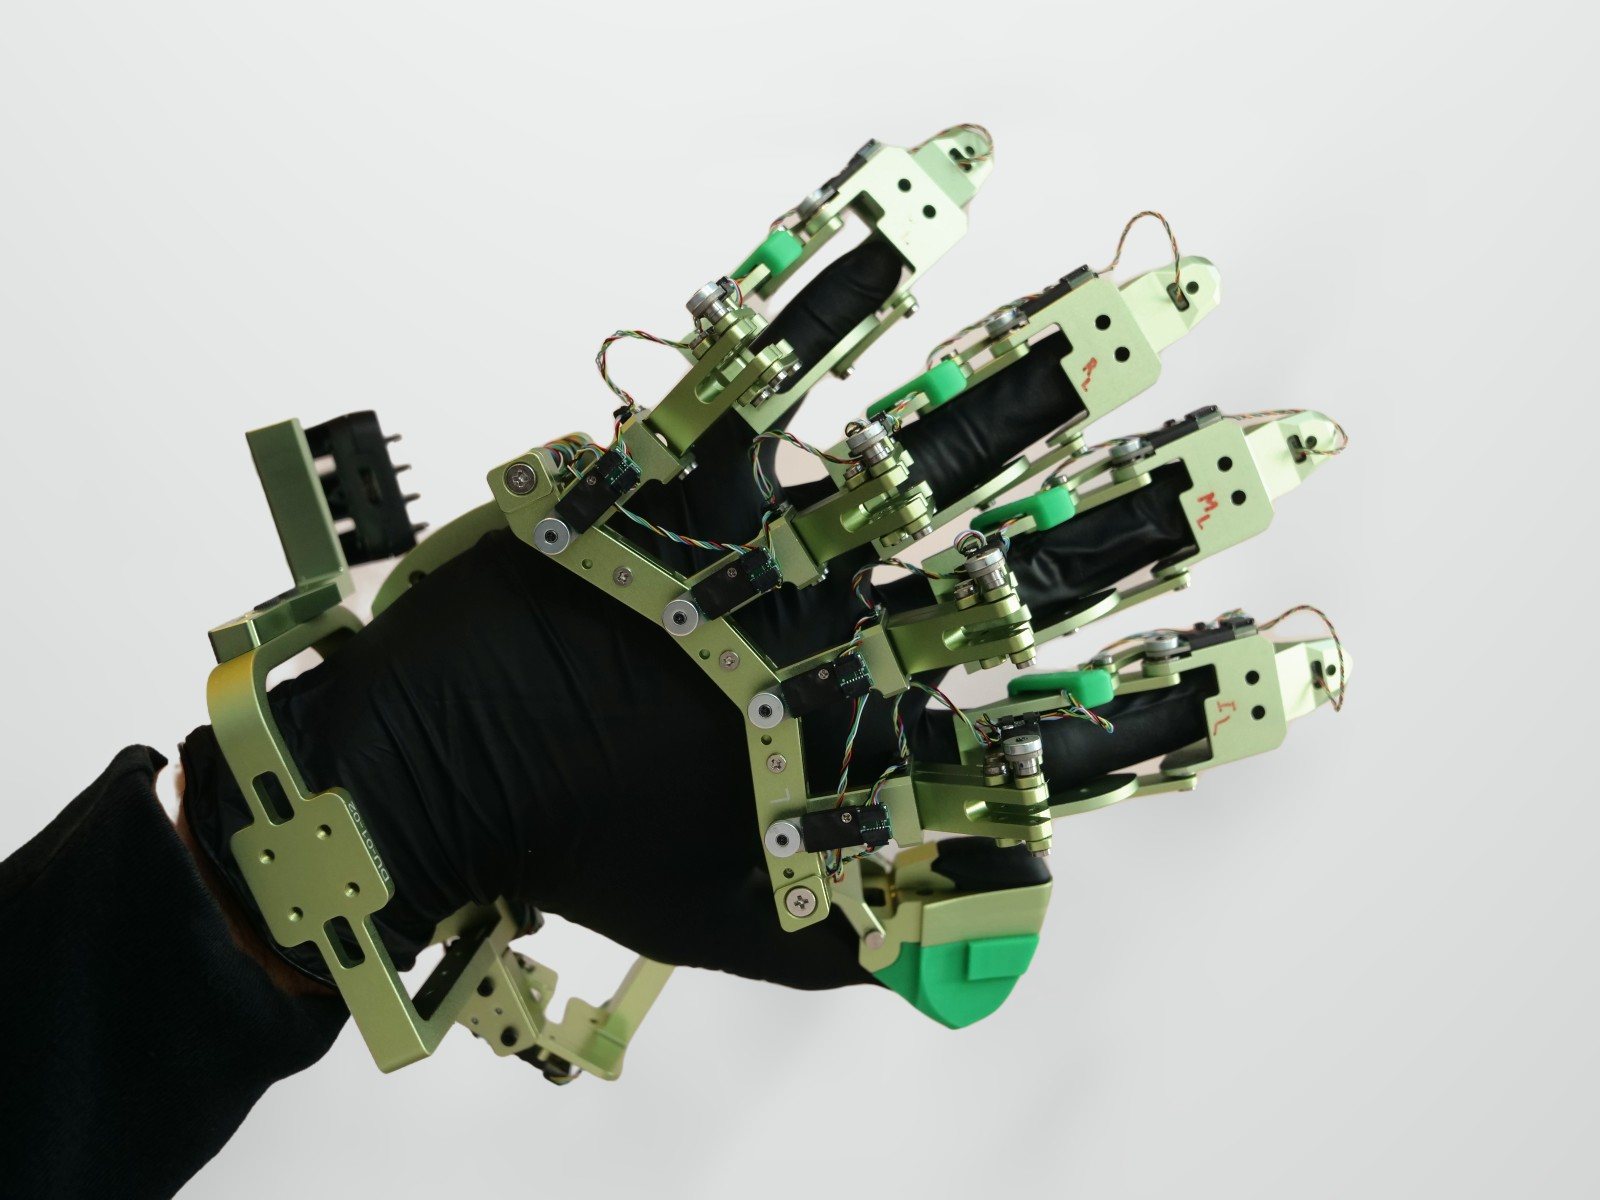
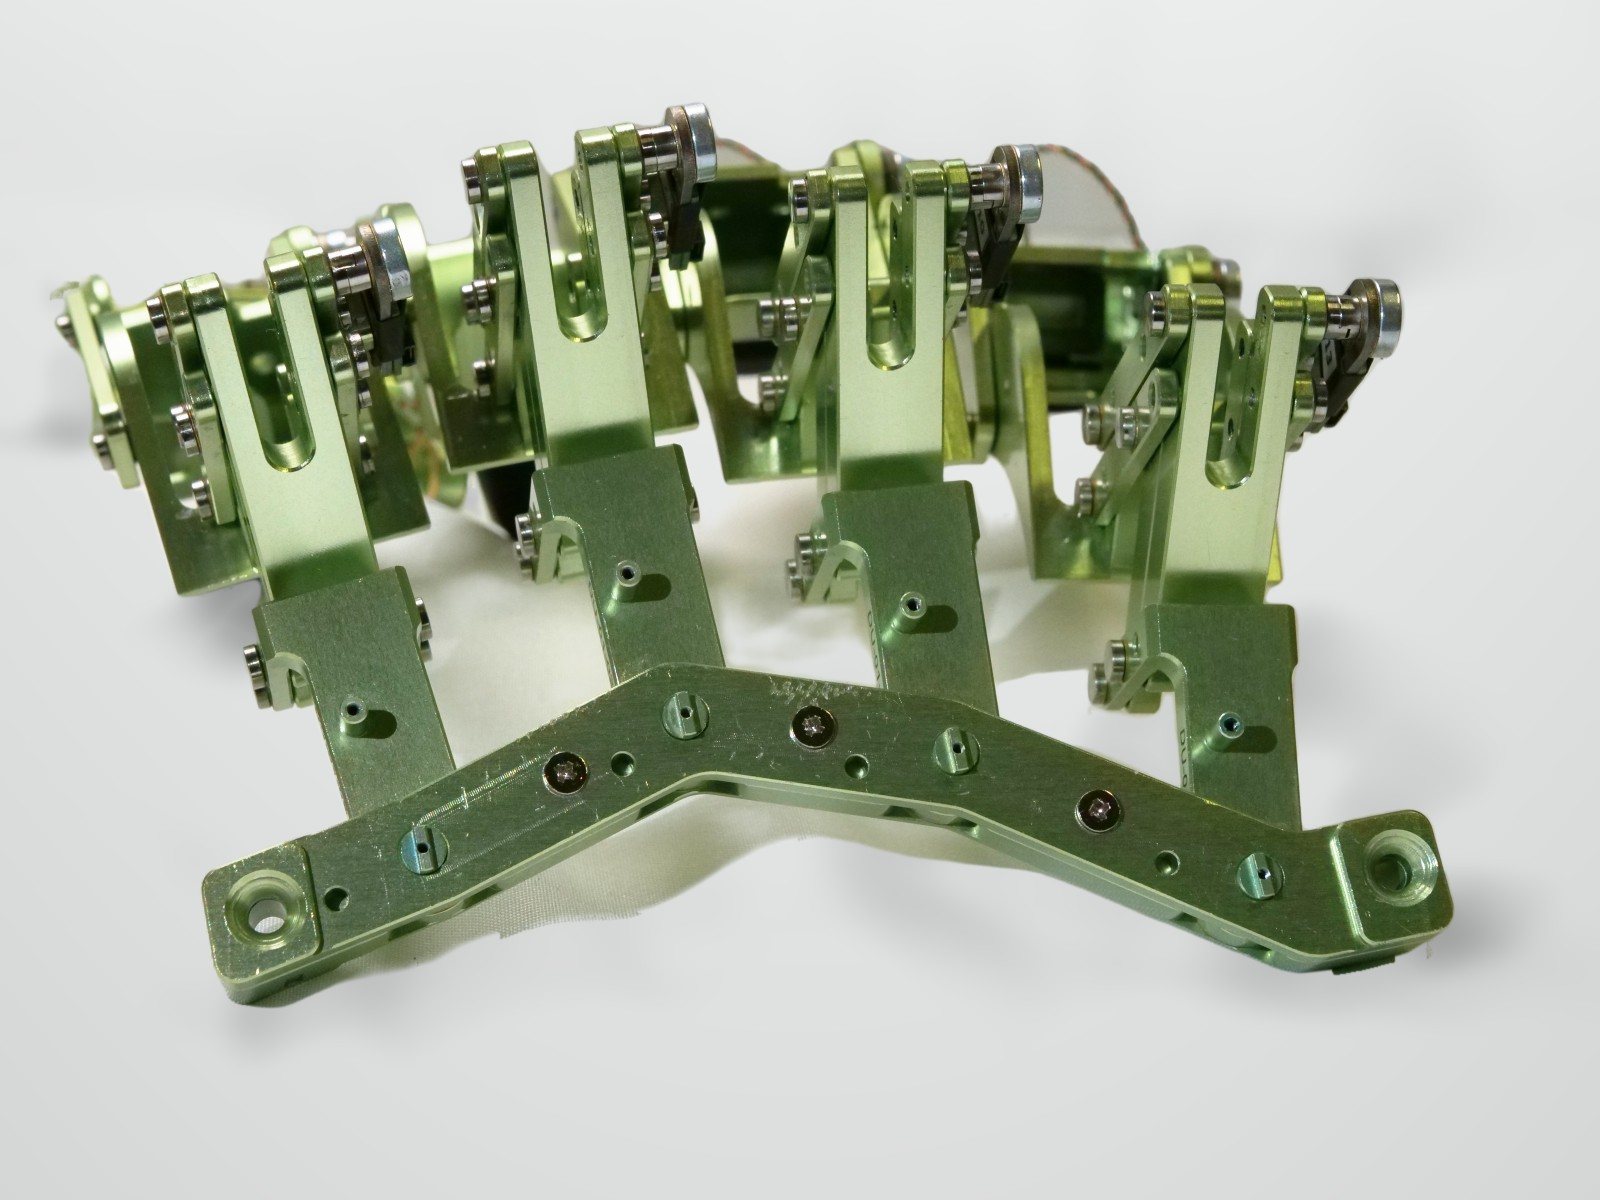
GEAR DexUMI photos and videos. Fingers closing into a fist and opening again, seen from the side, half speed
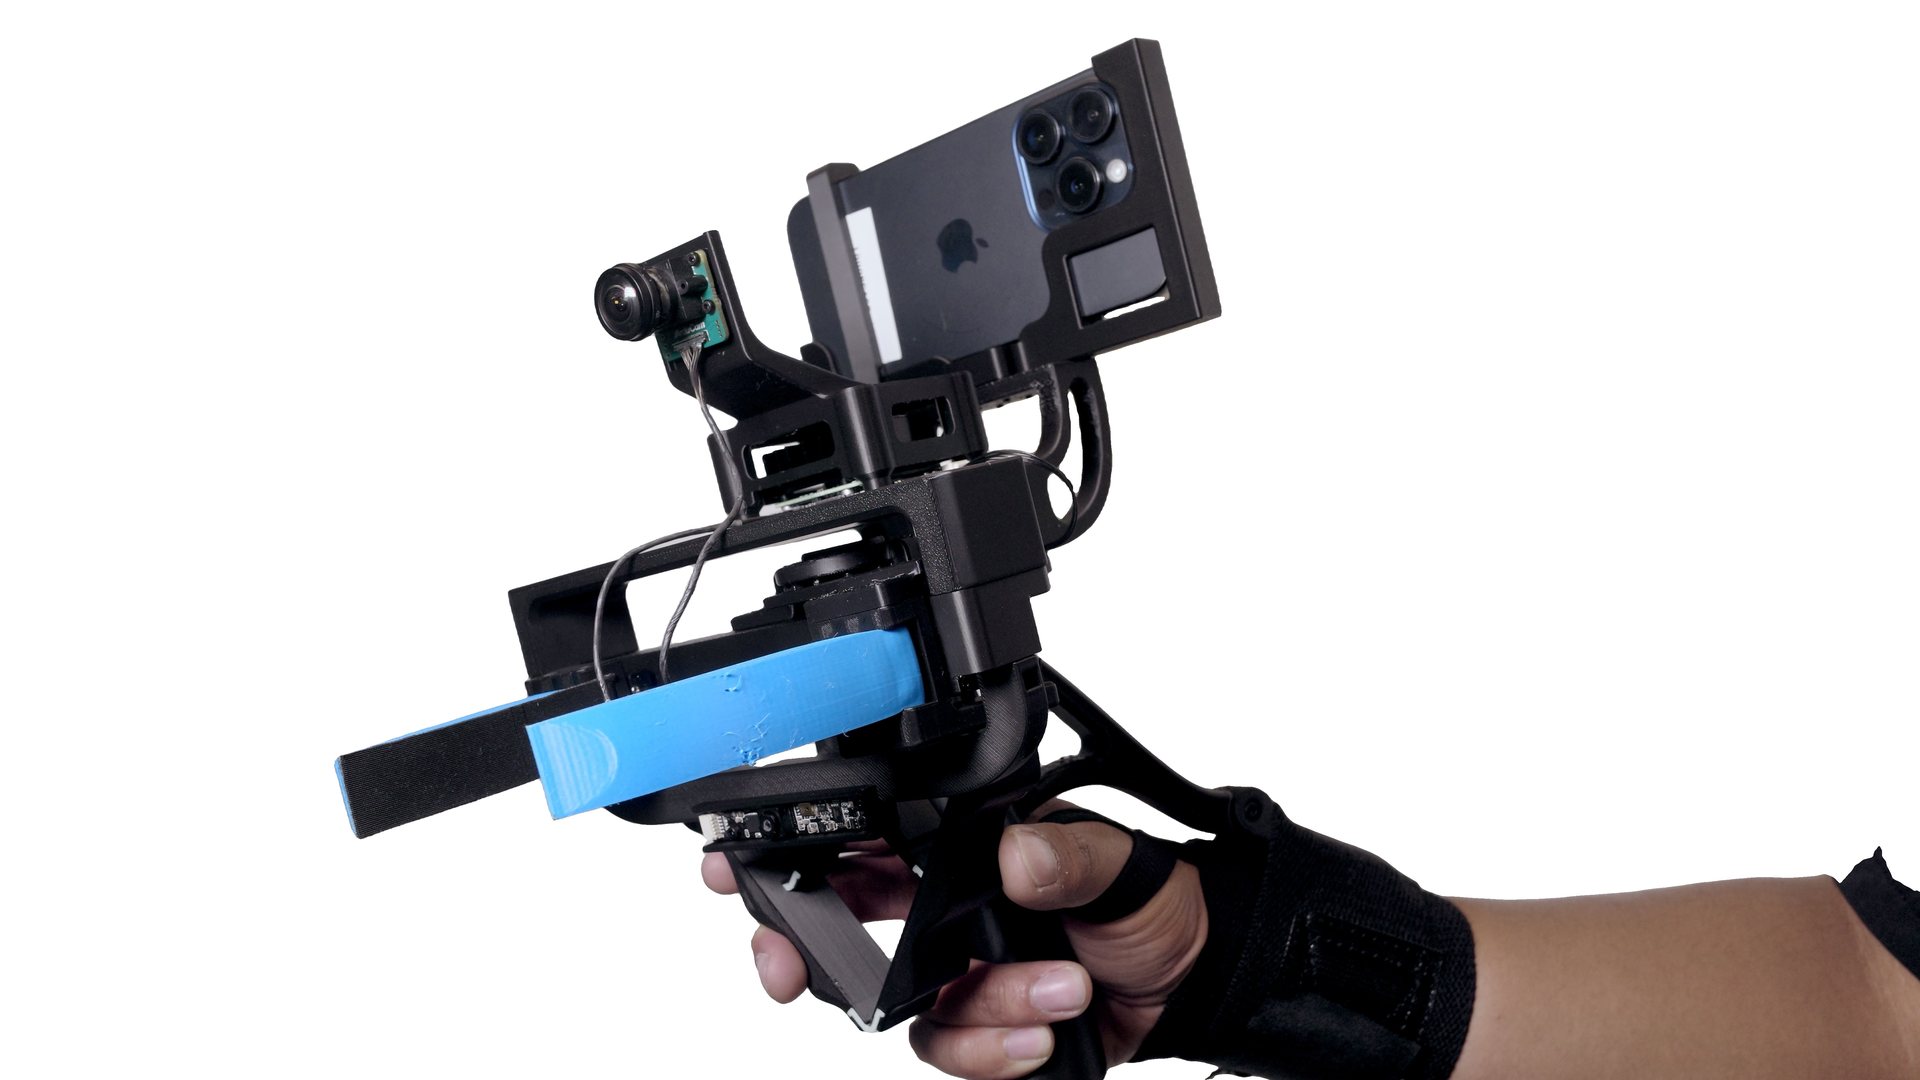
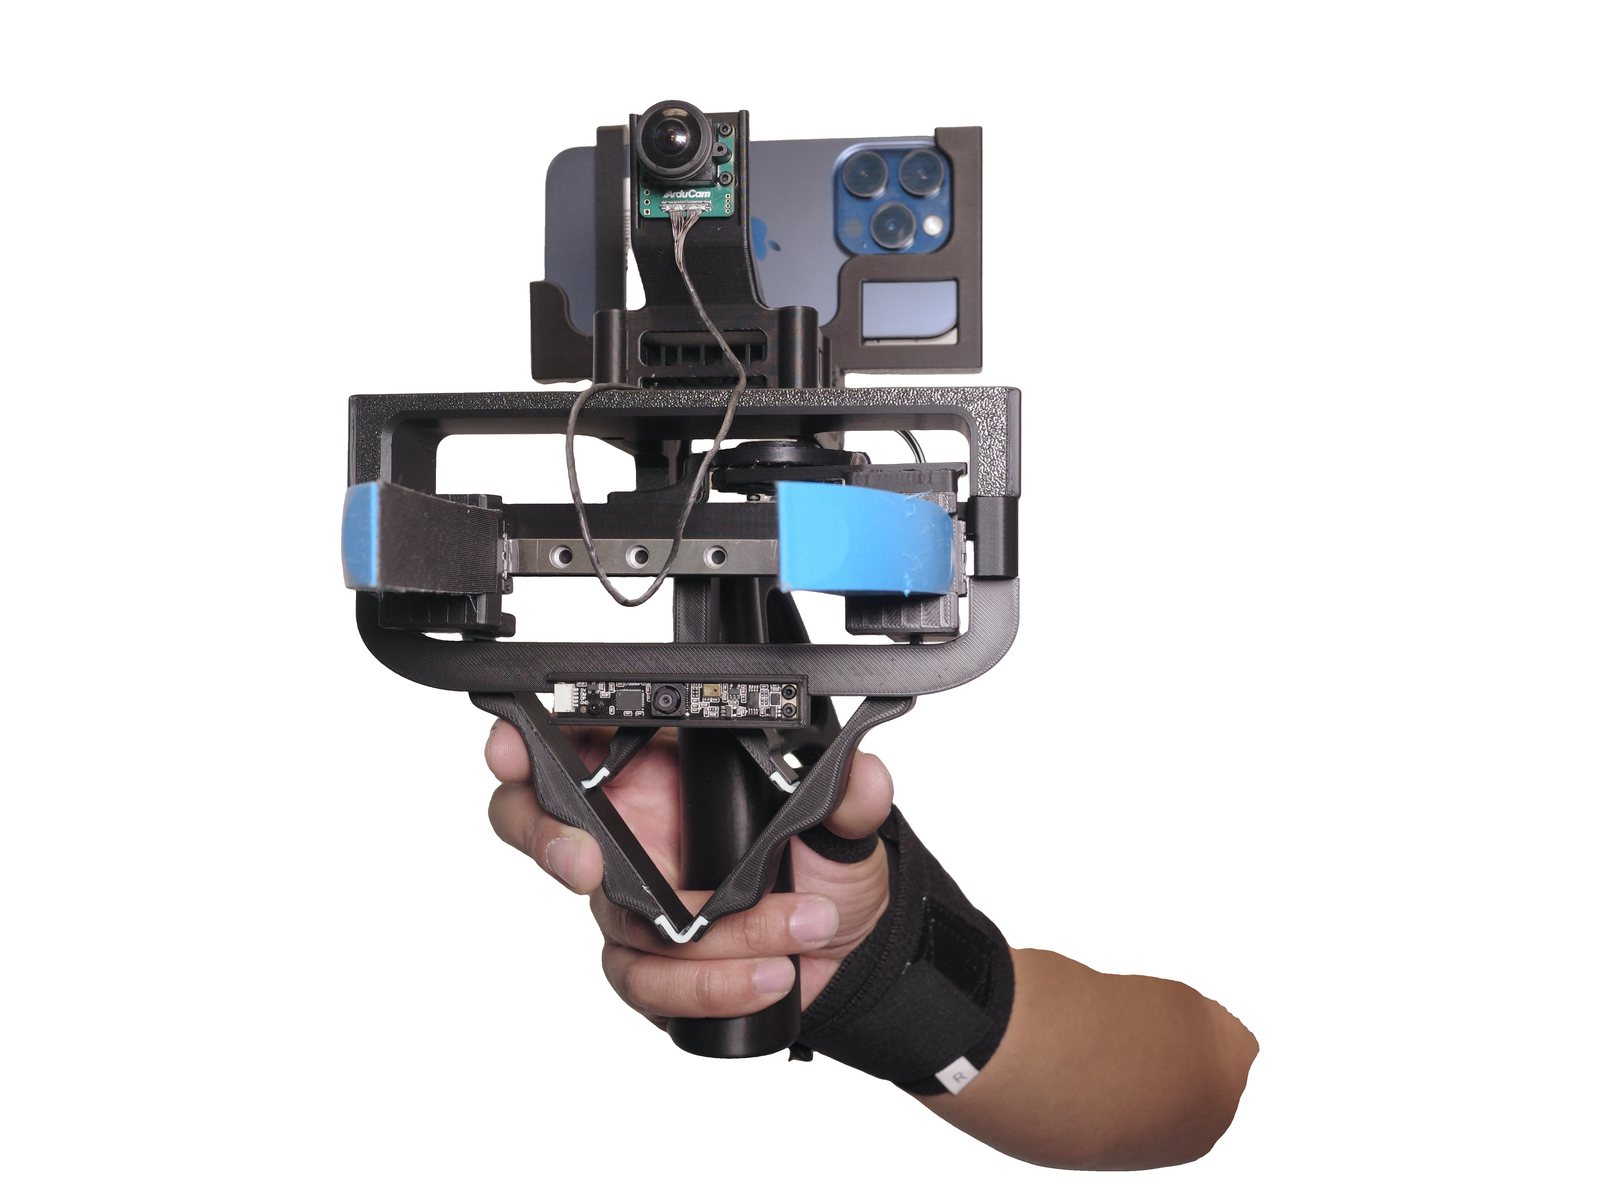
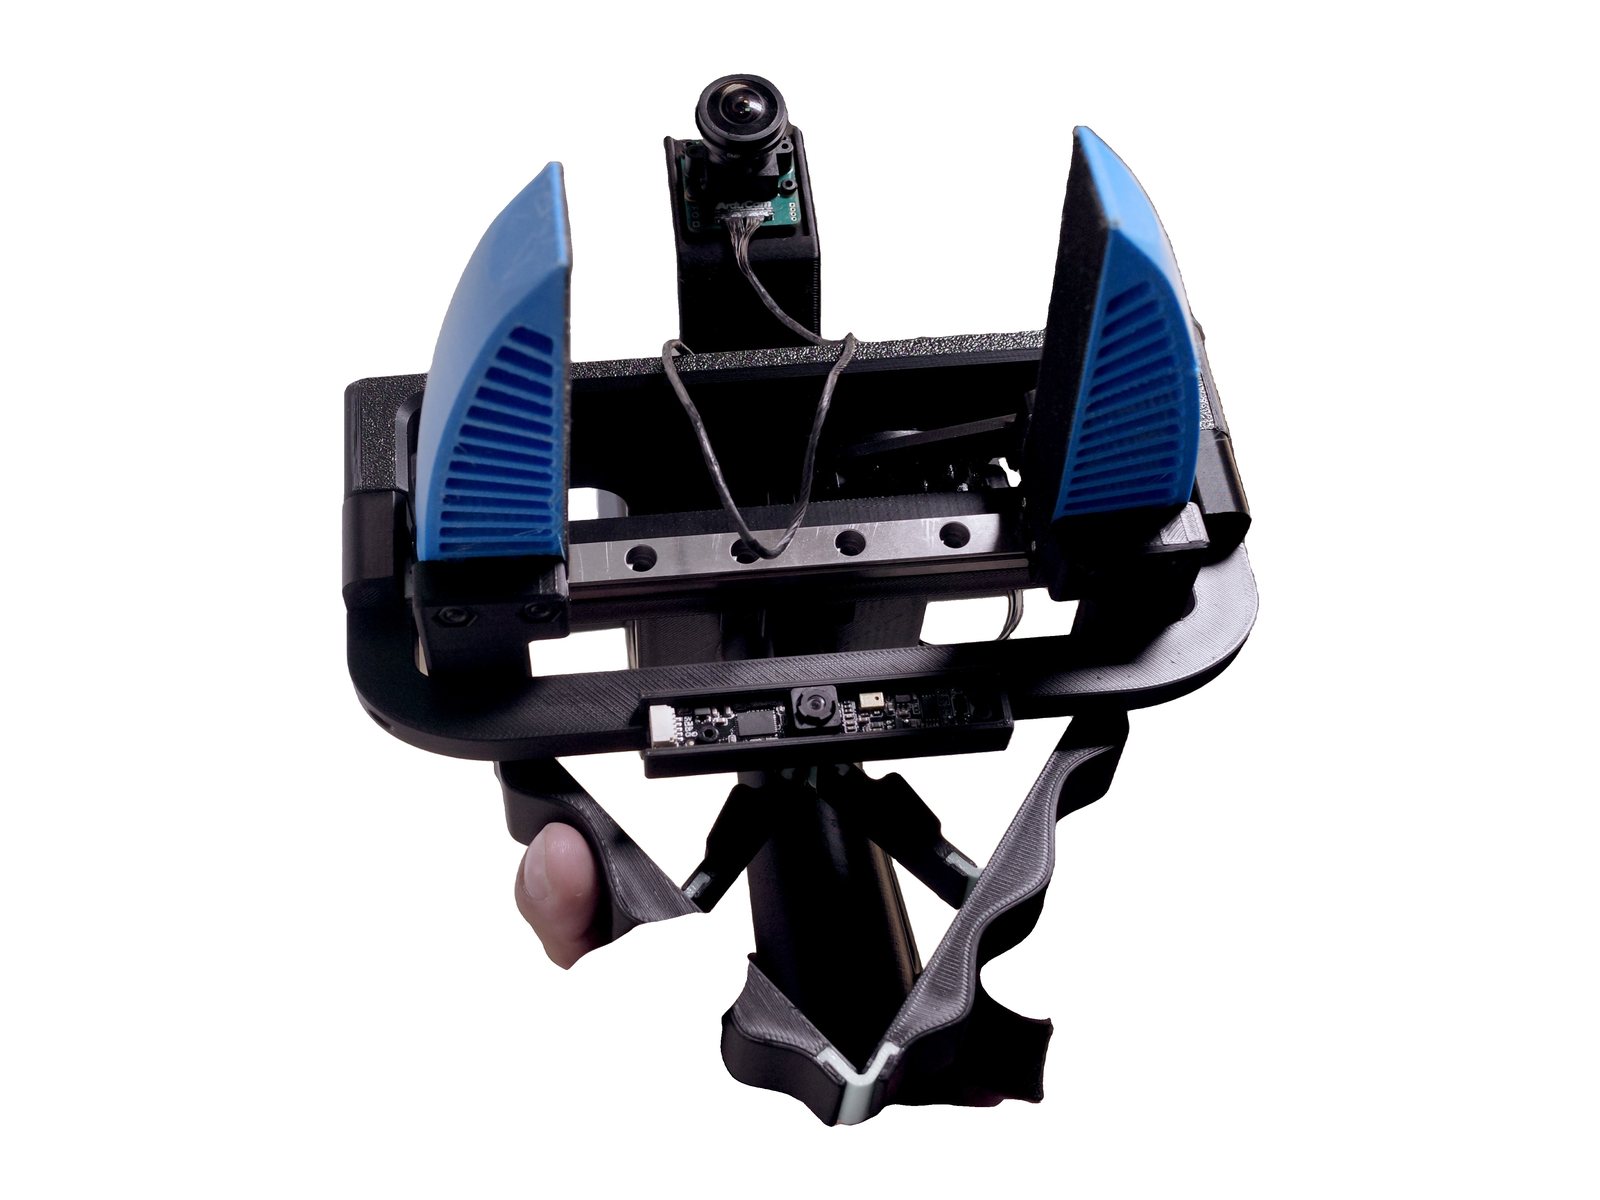
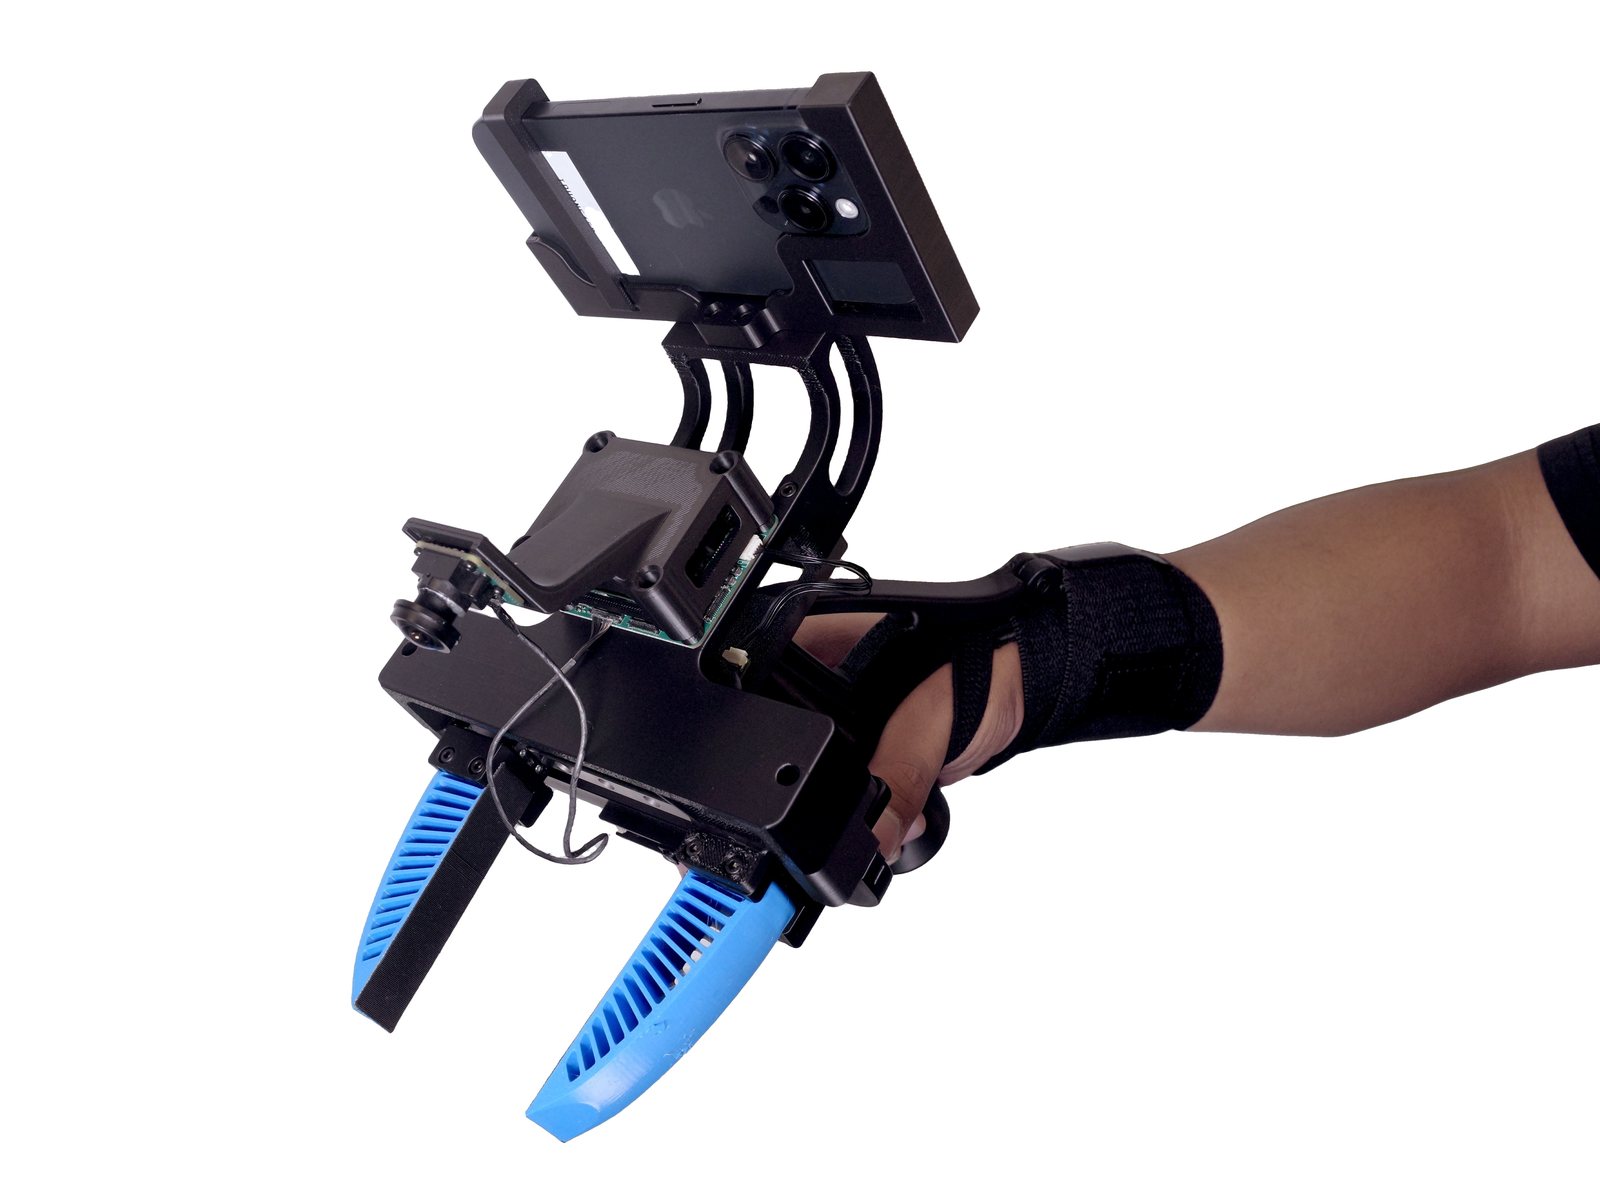
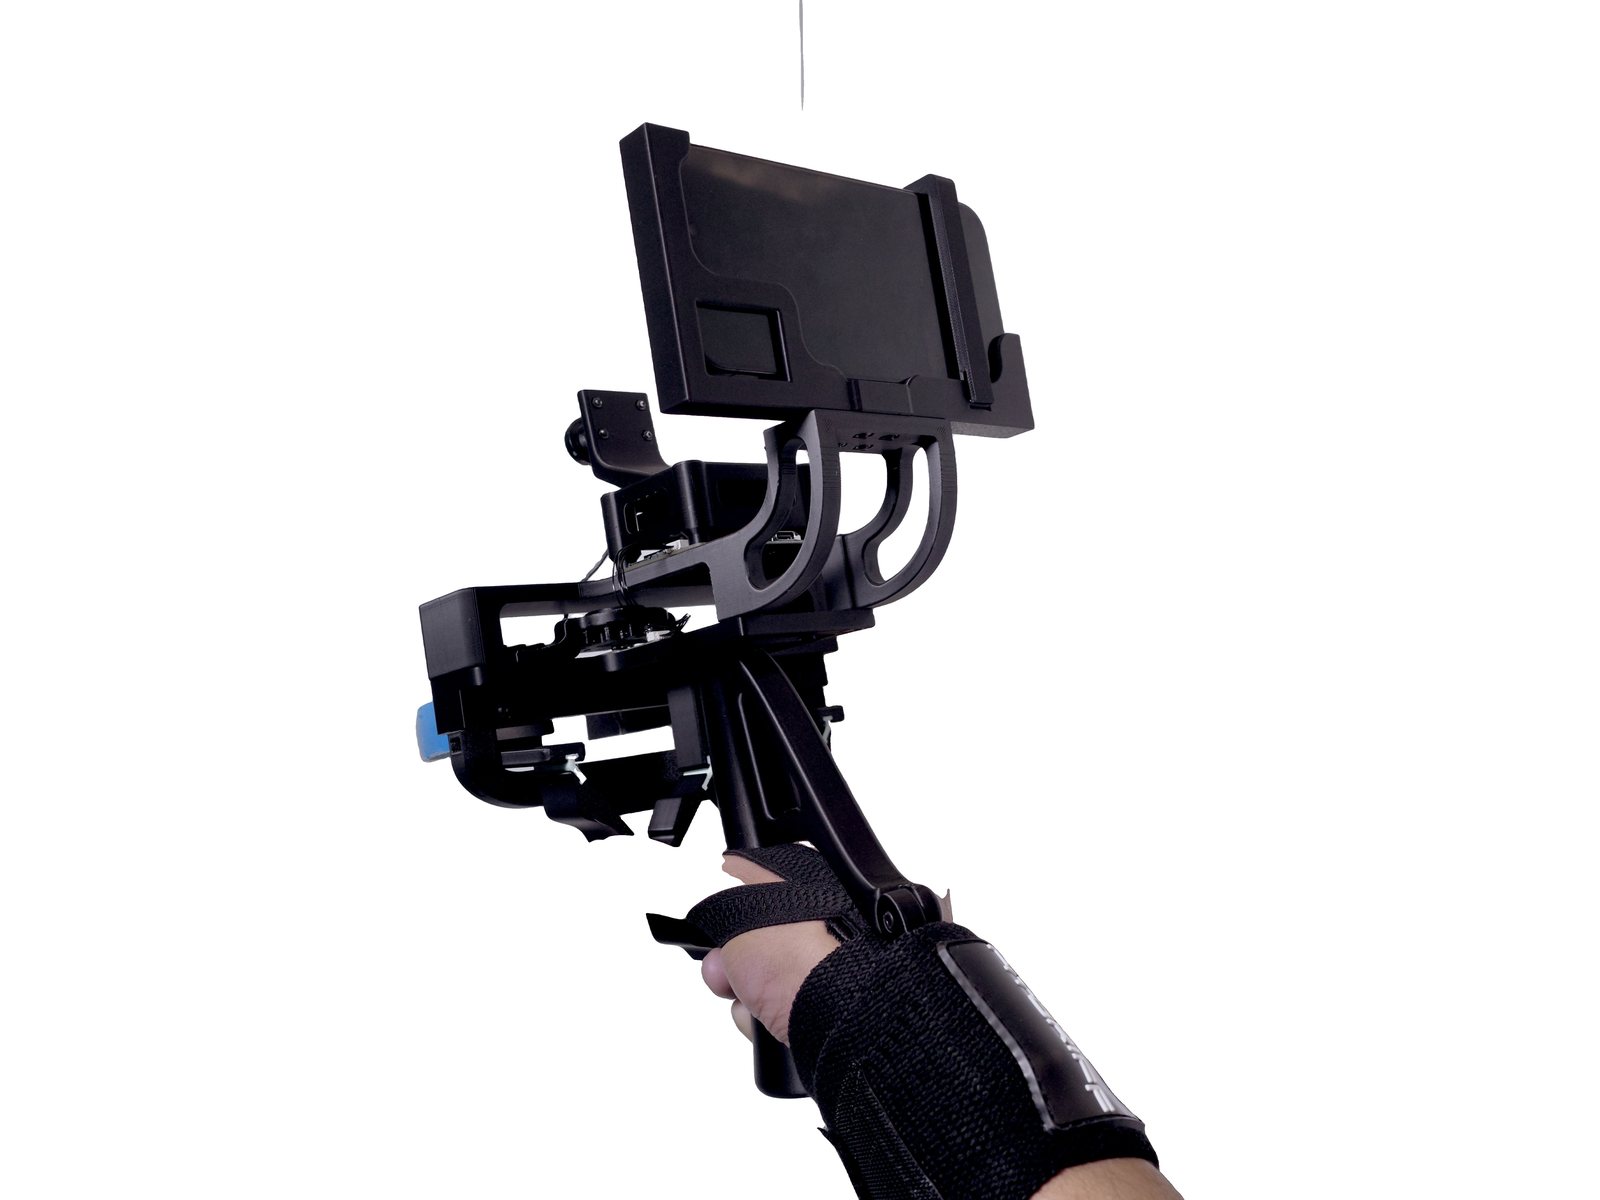
GEAR UMI photos. Videos are coming soon.
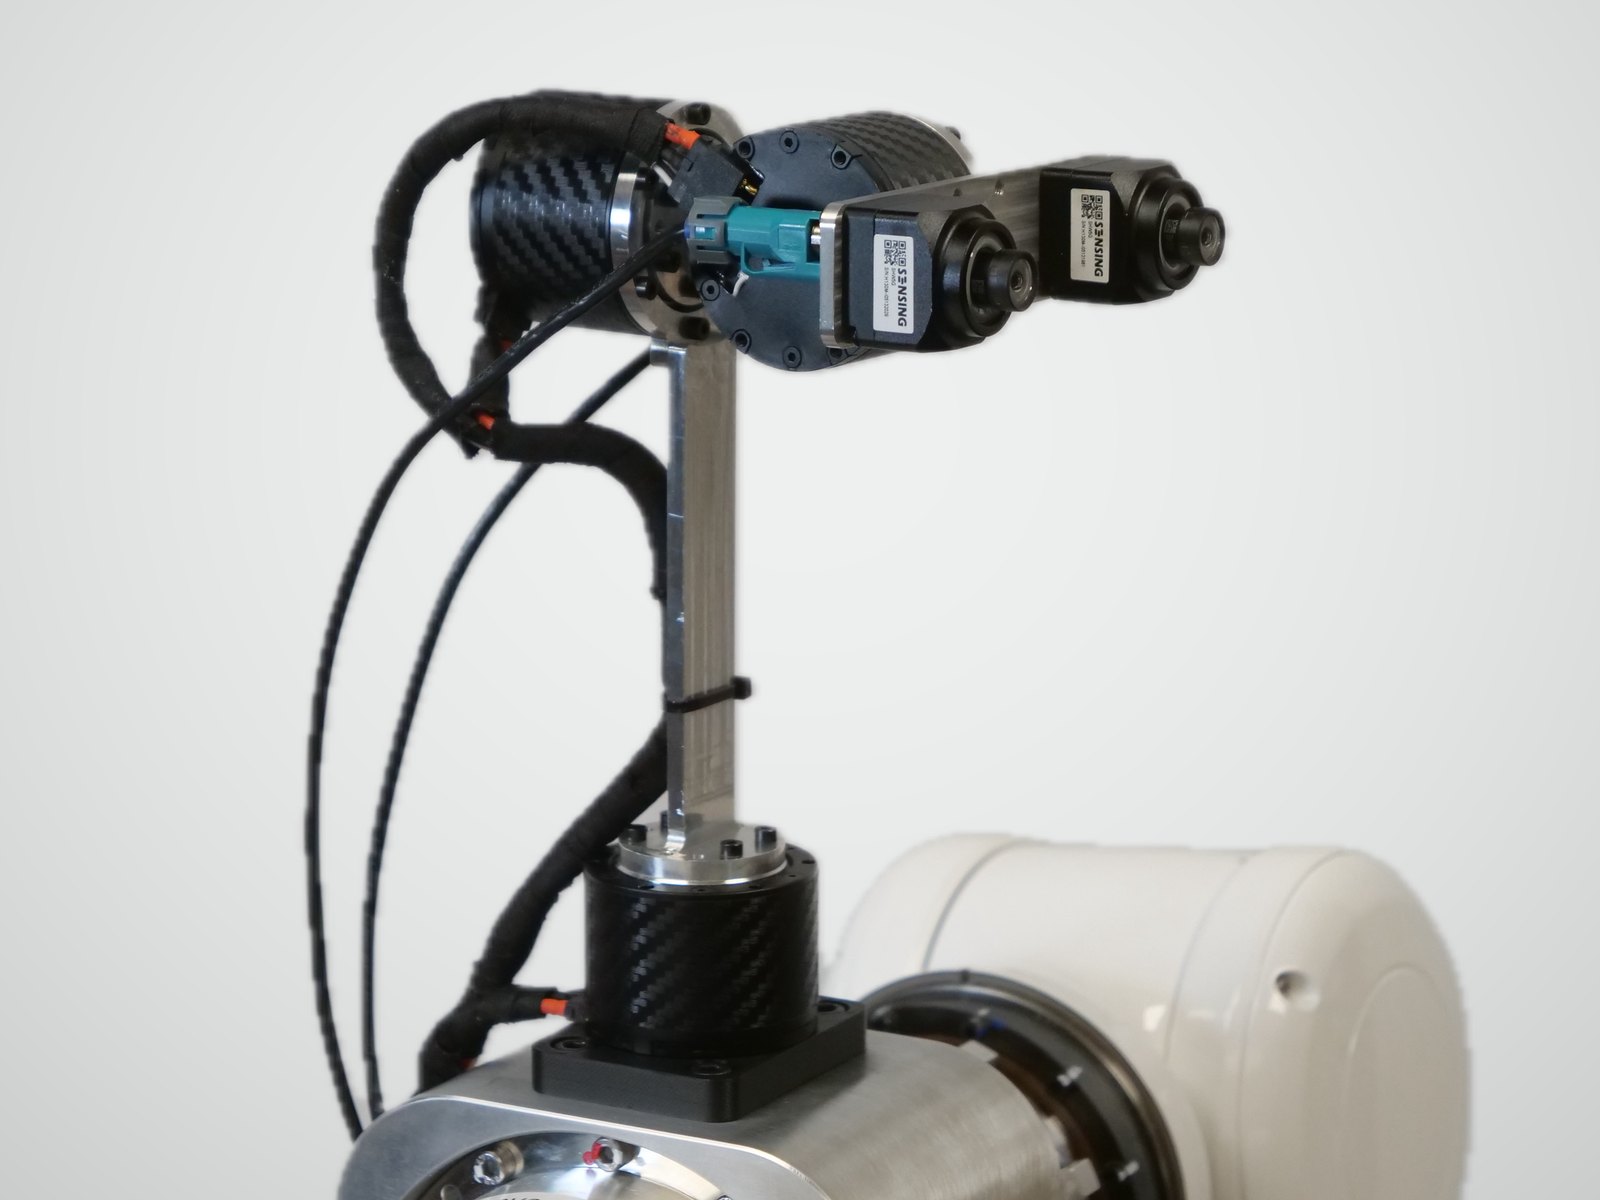
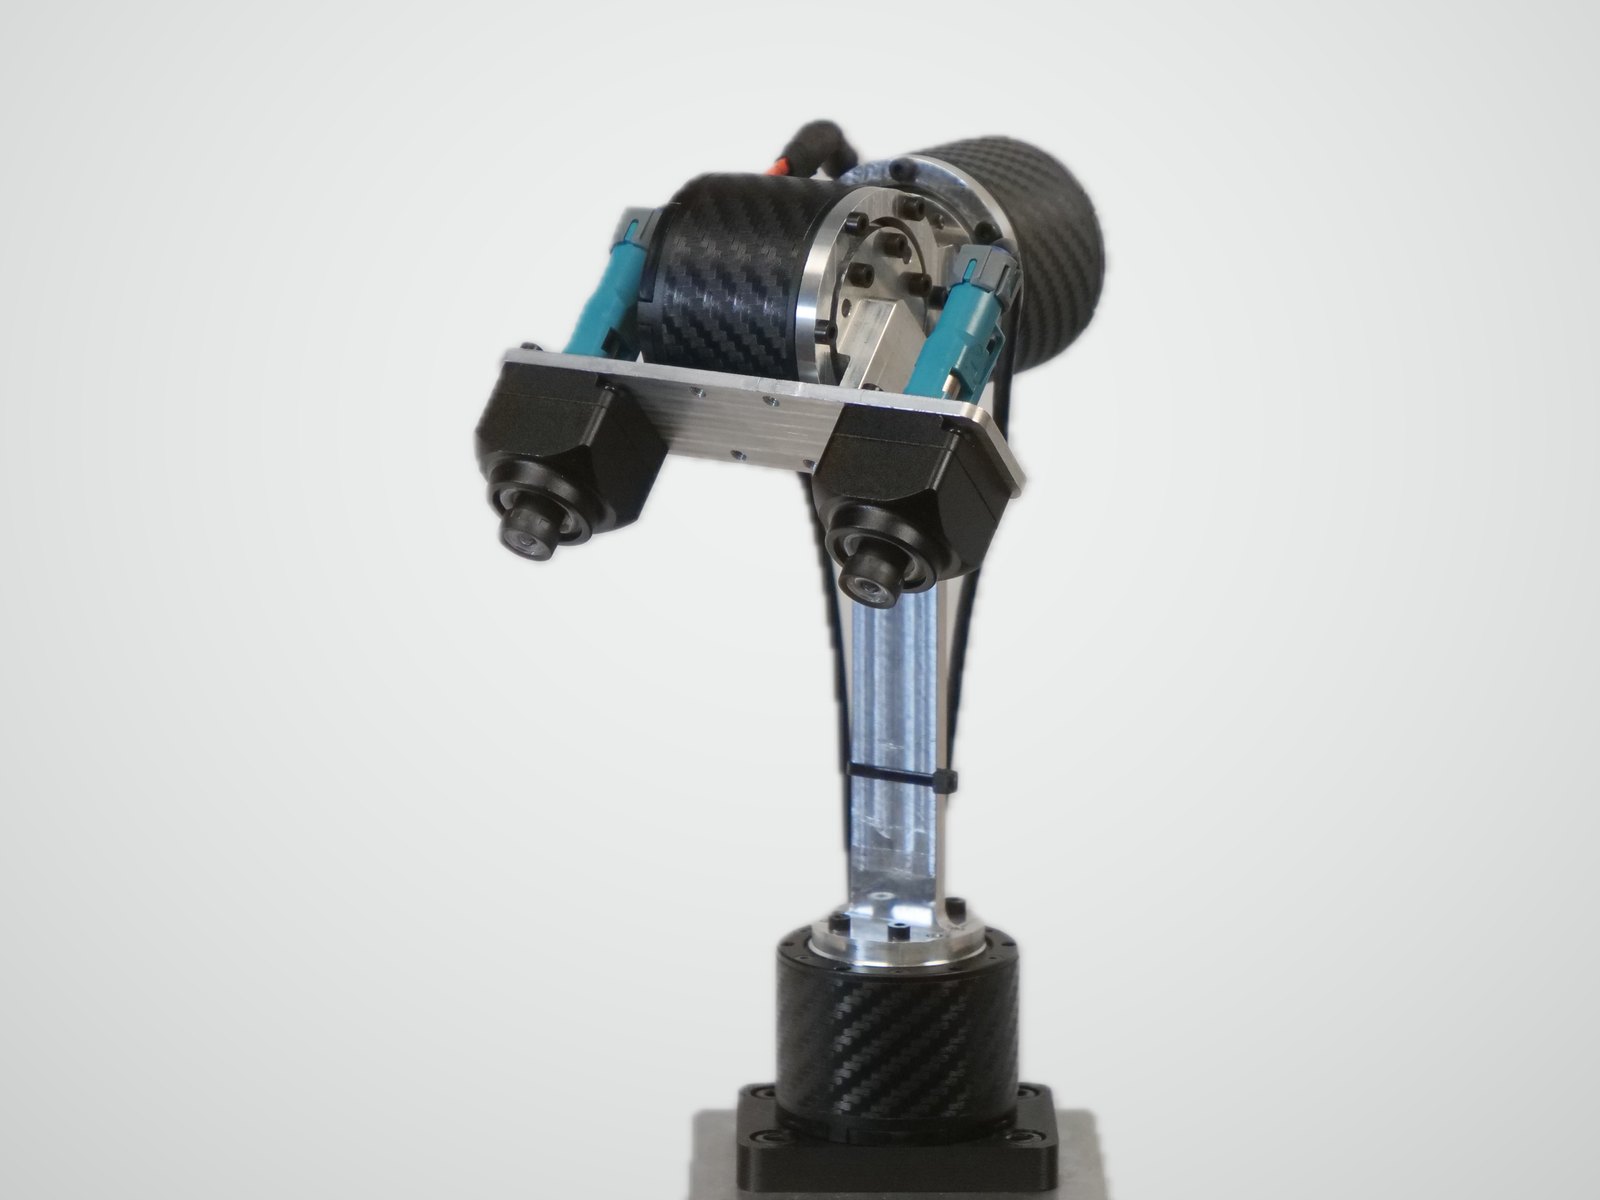
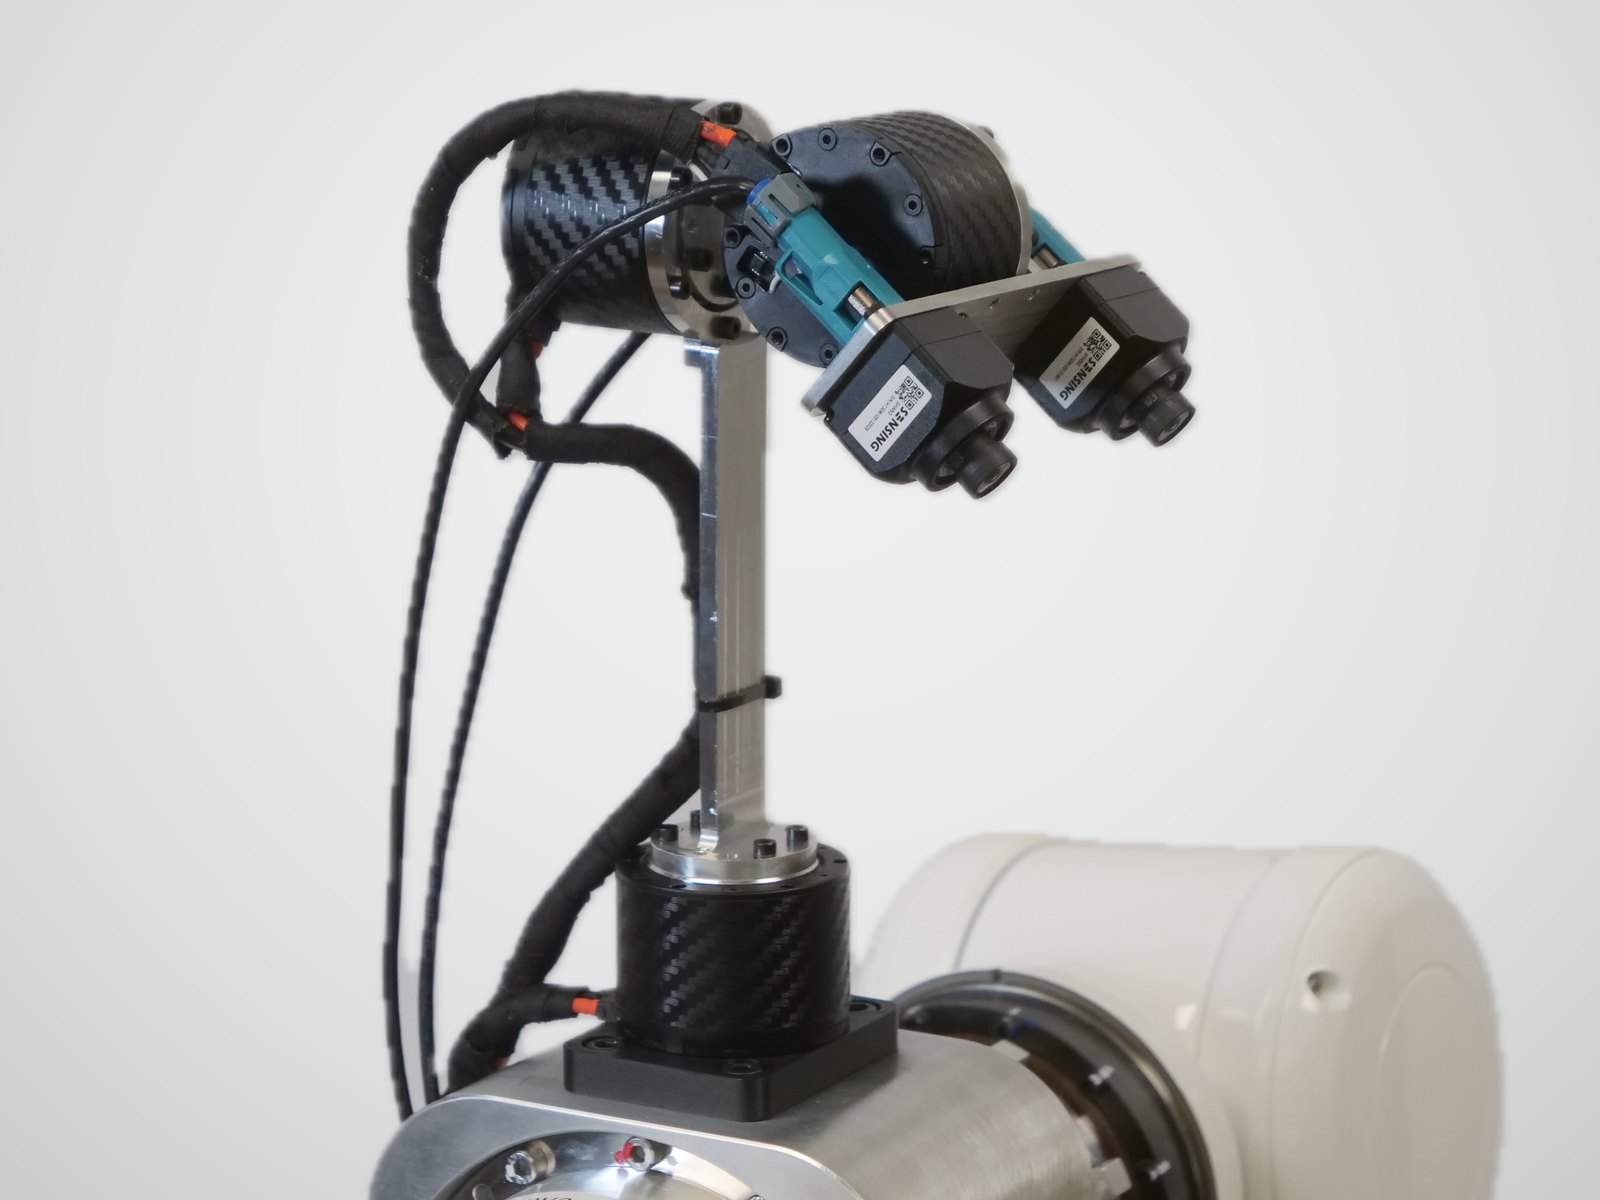
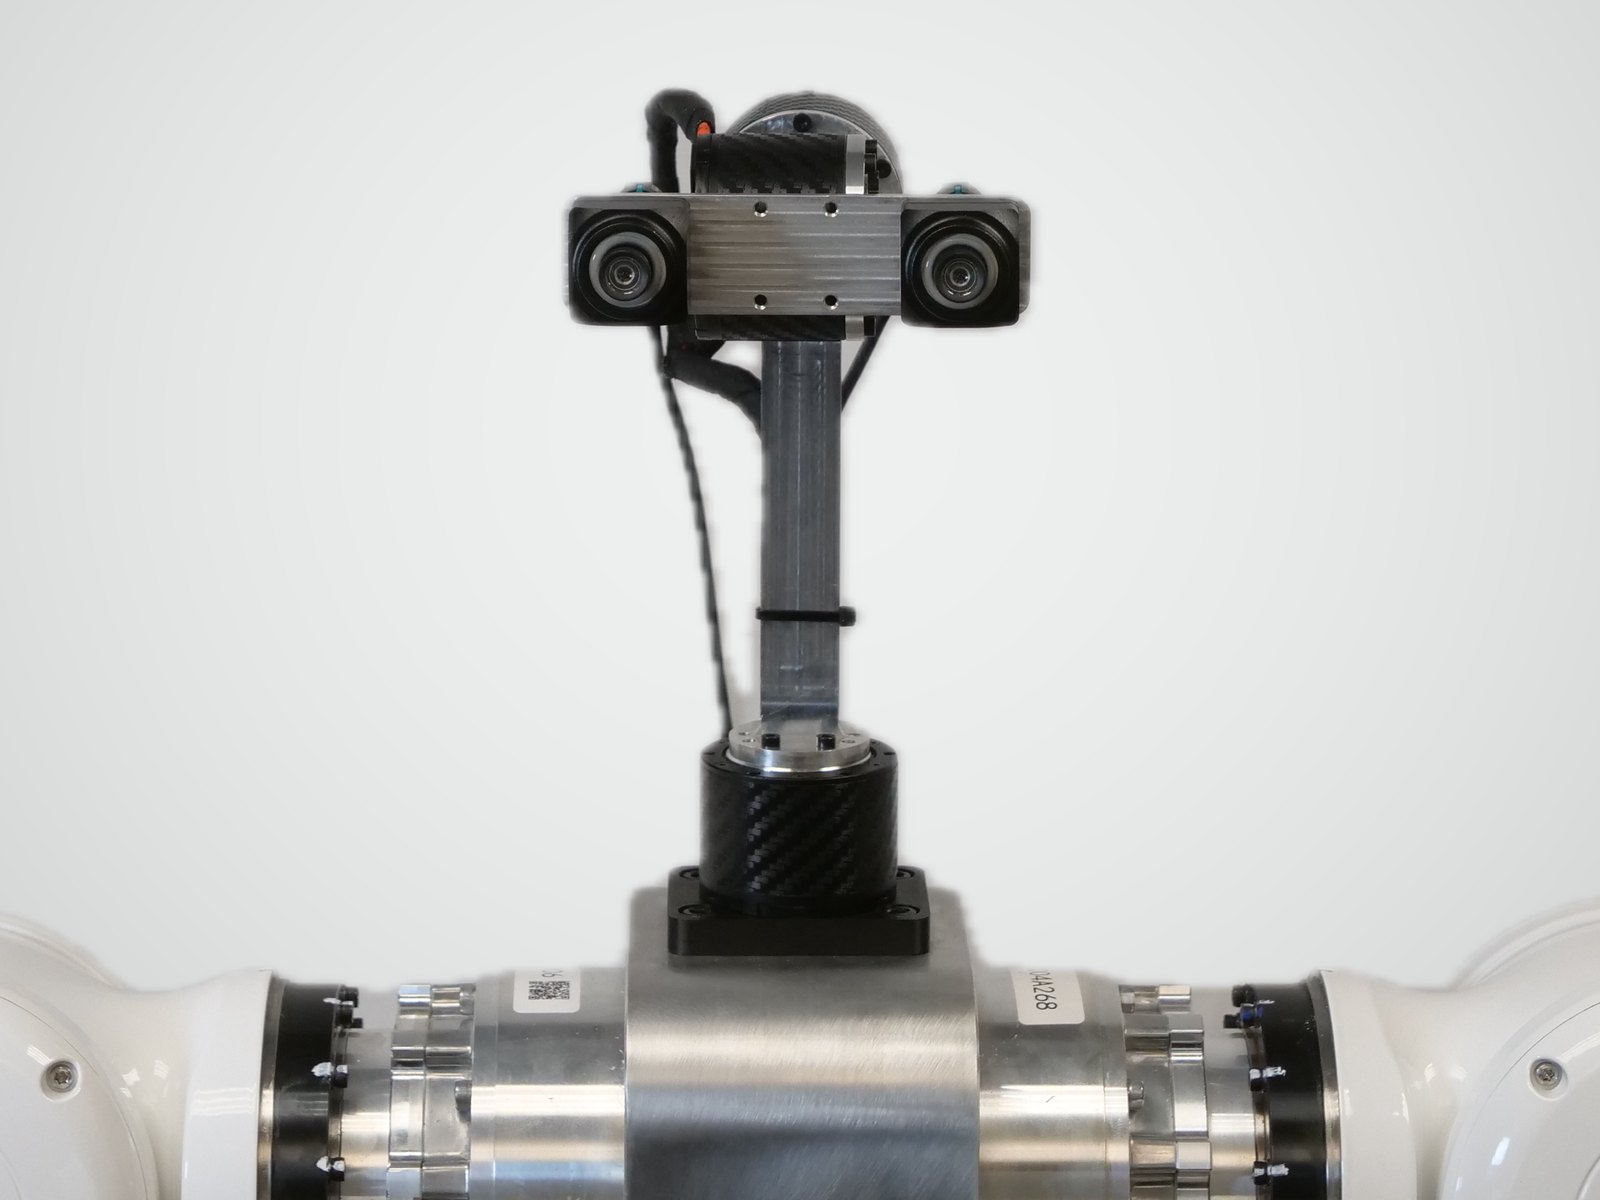
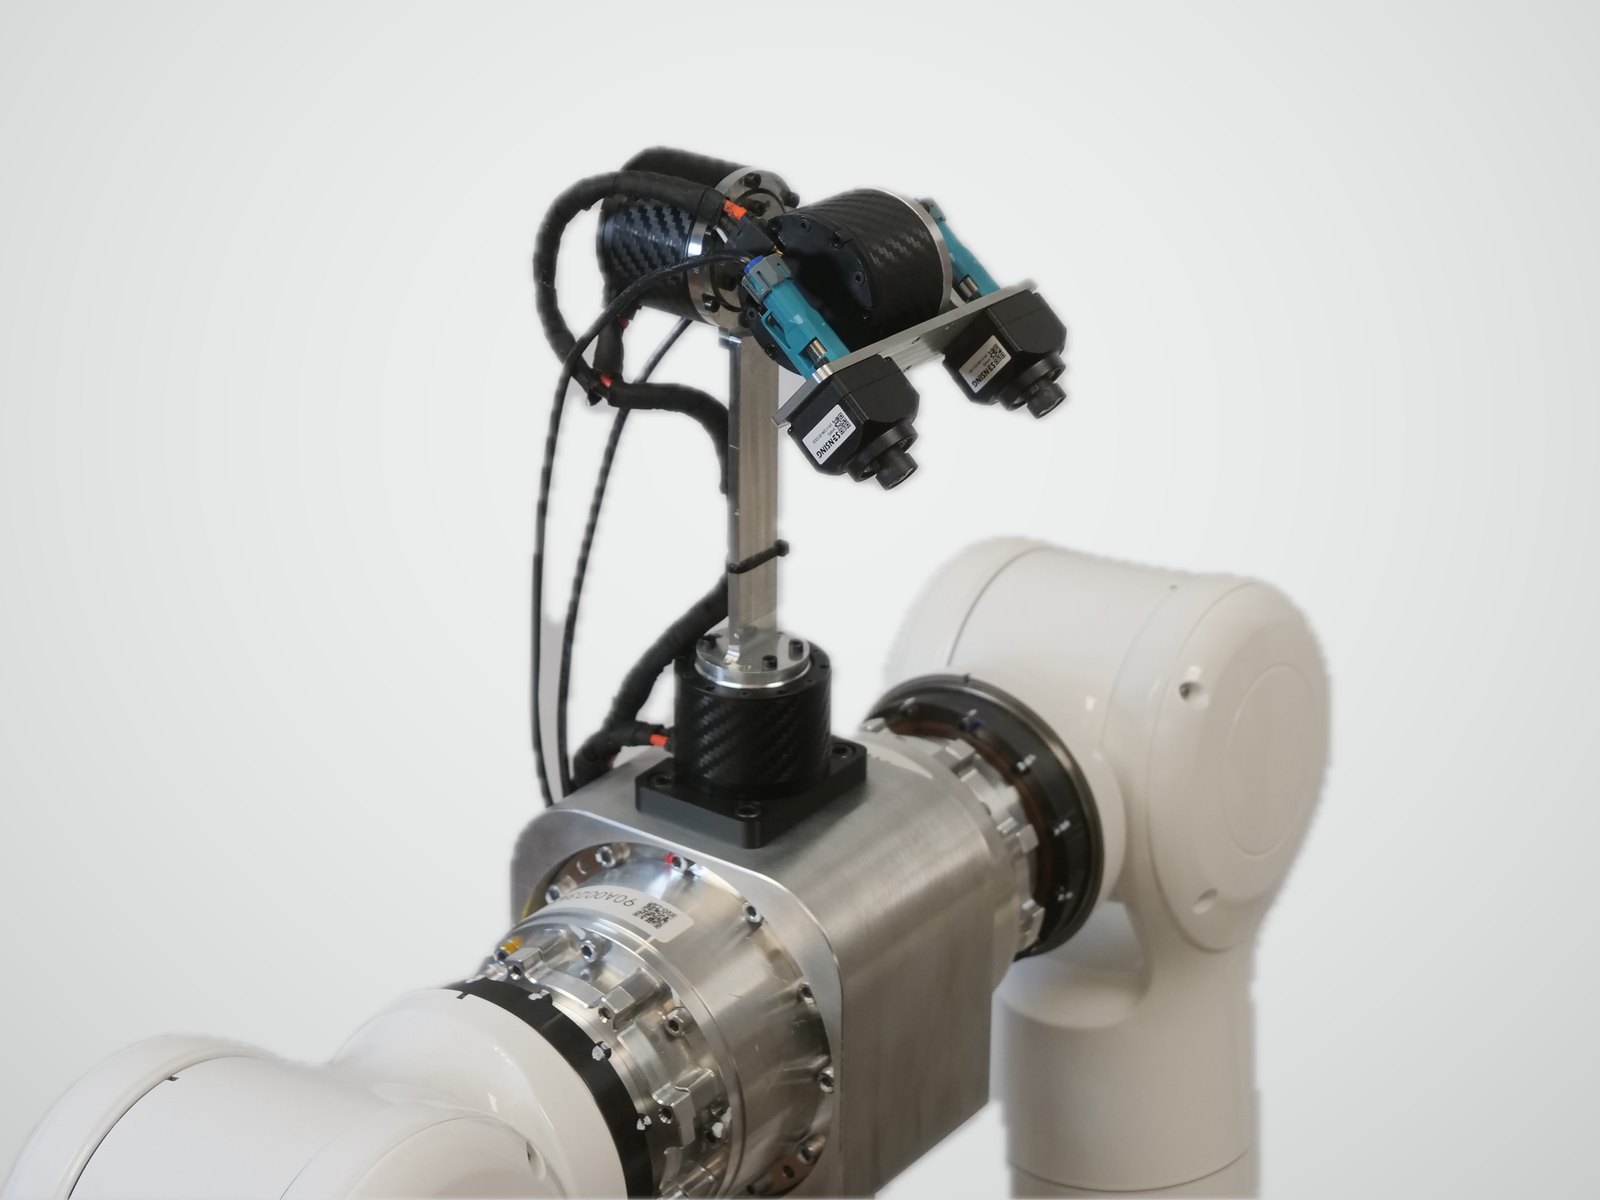
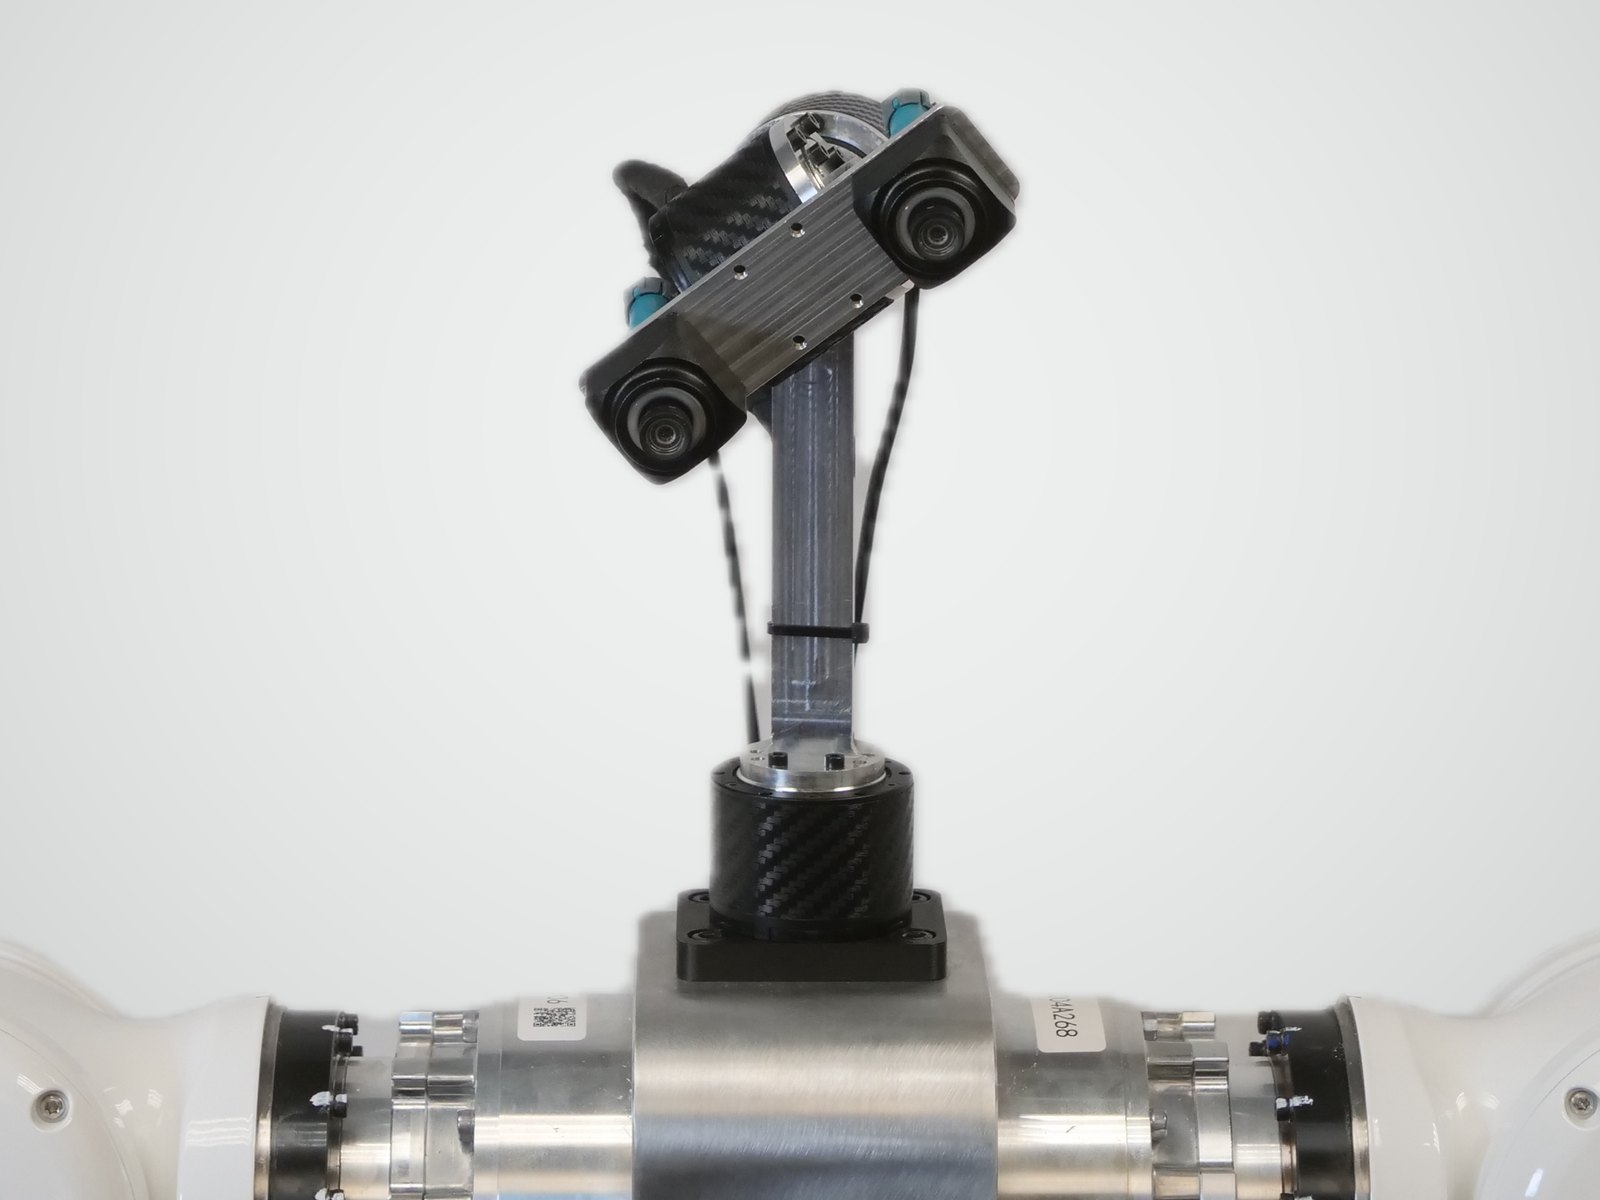
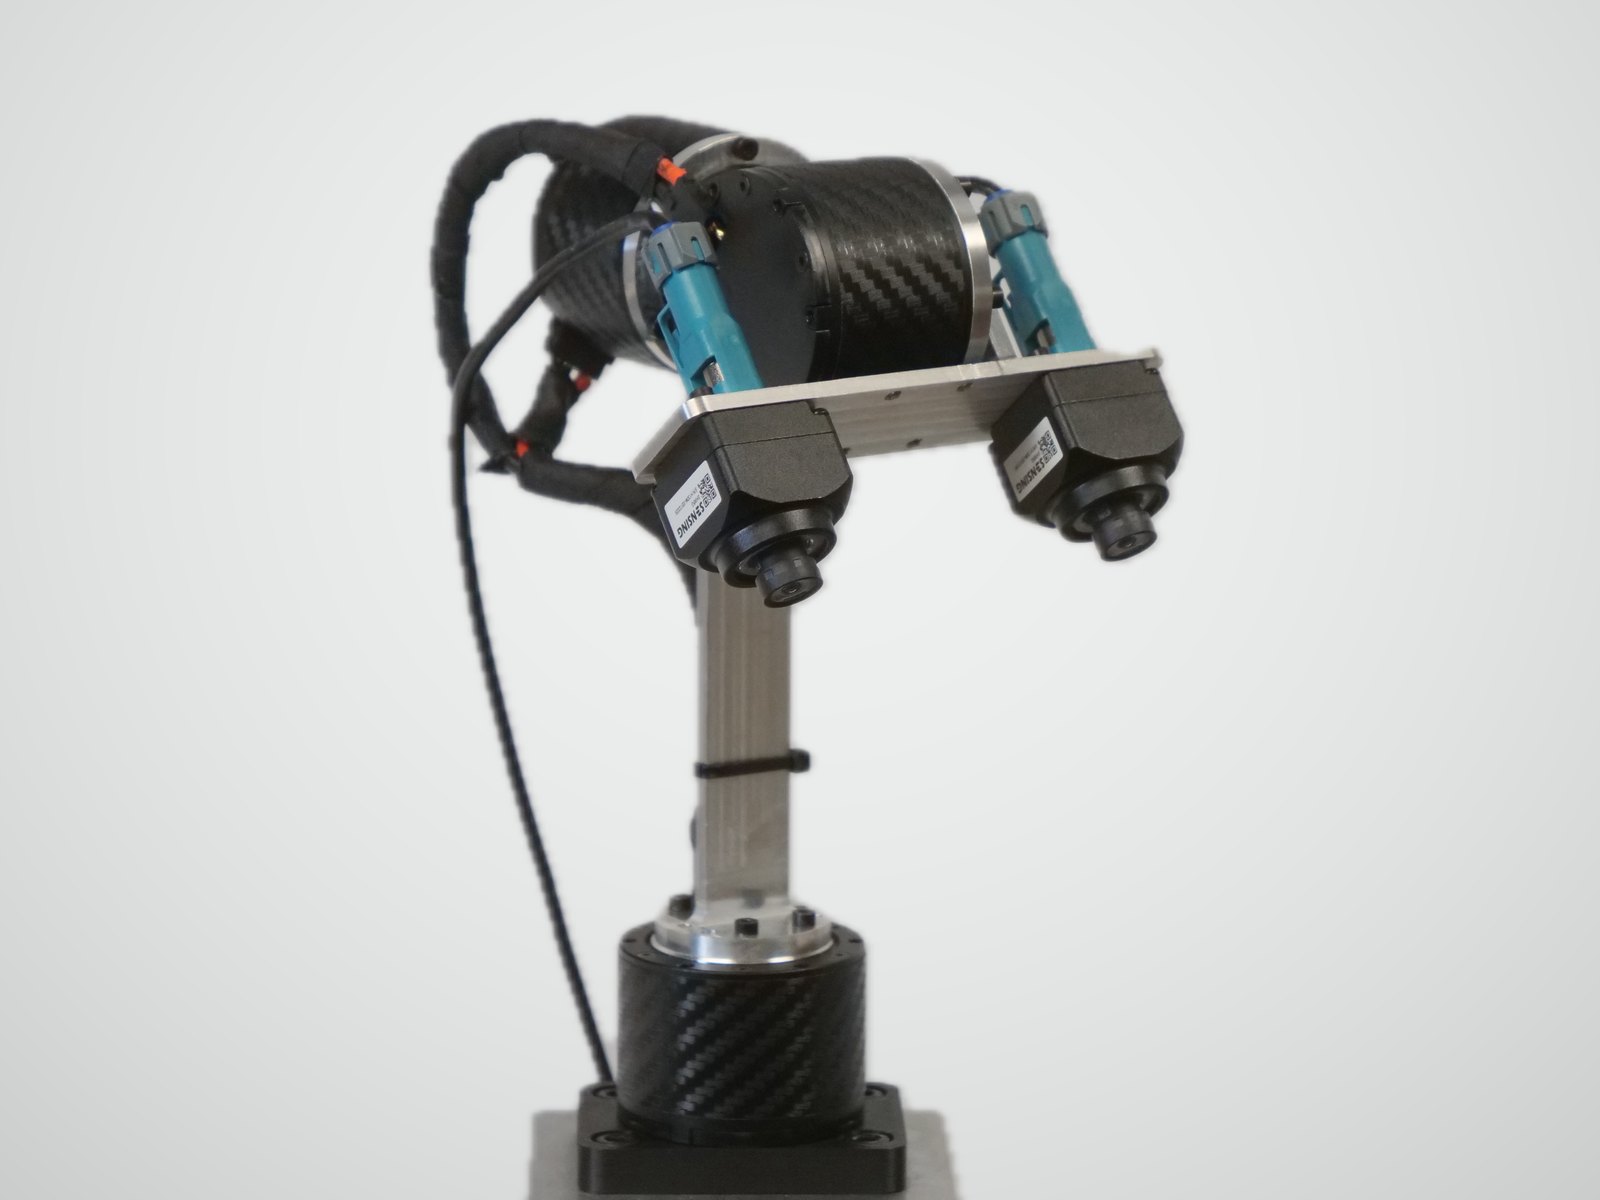
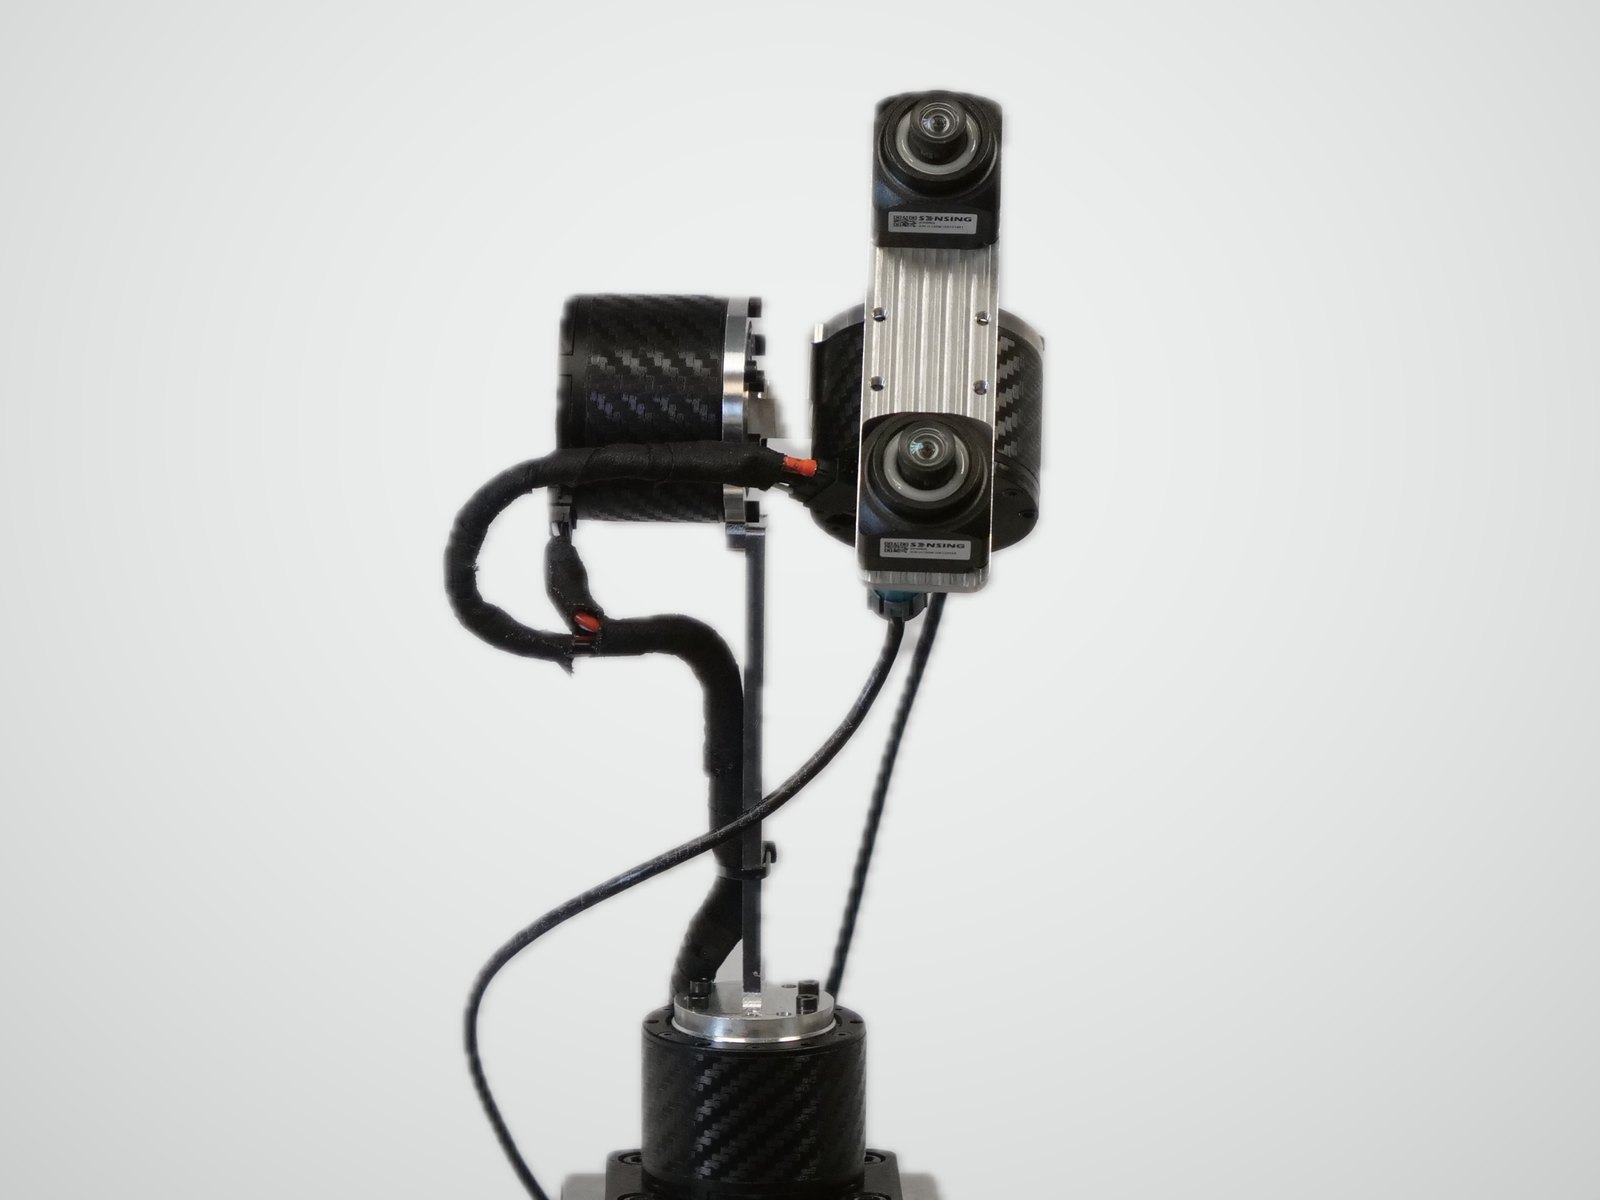
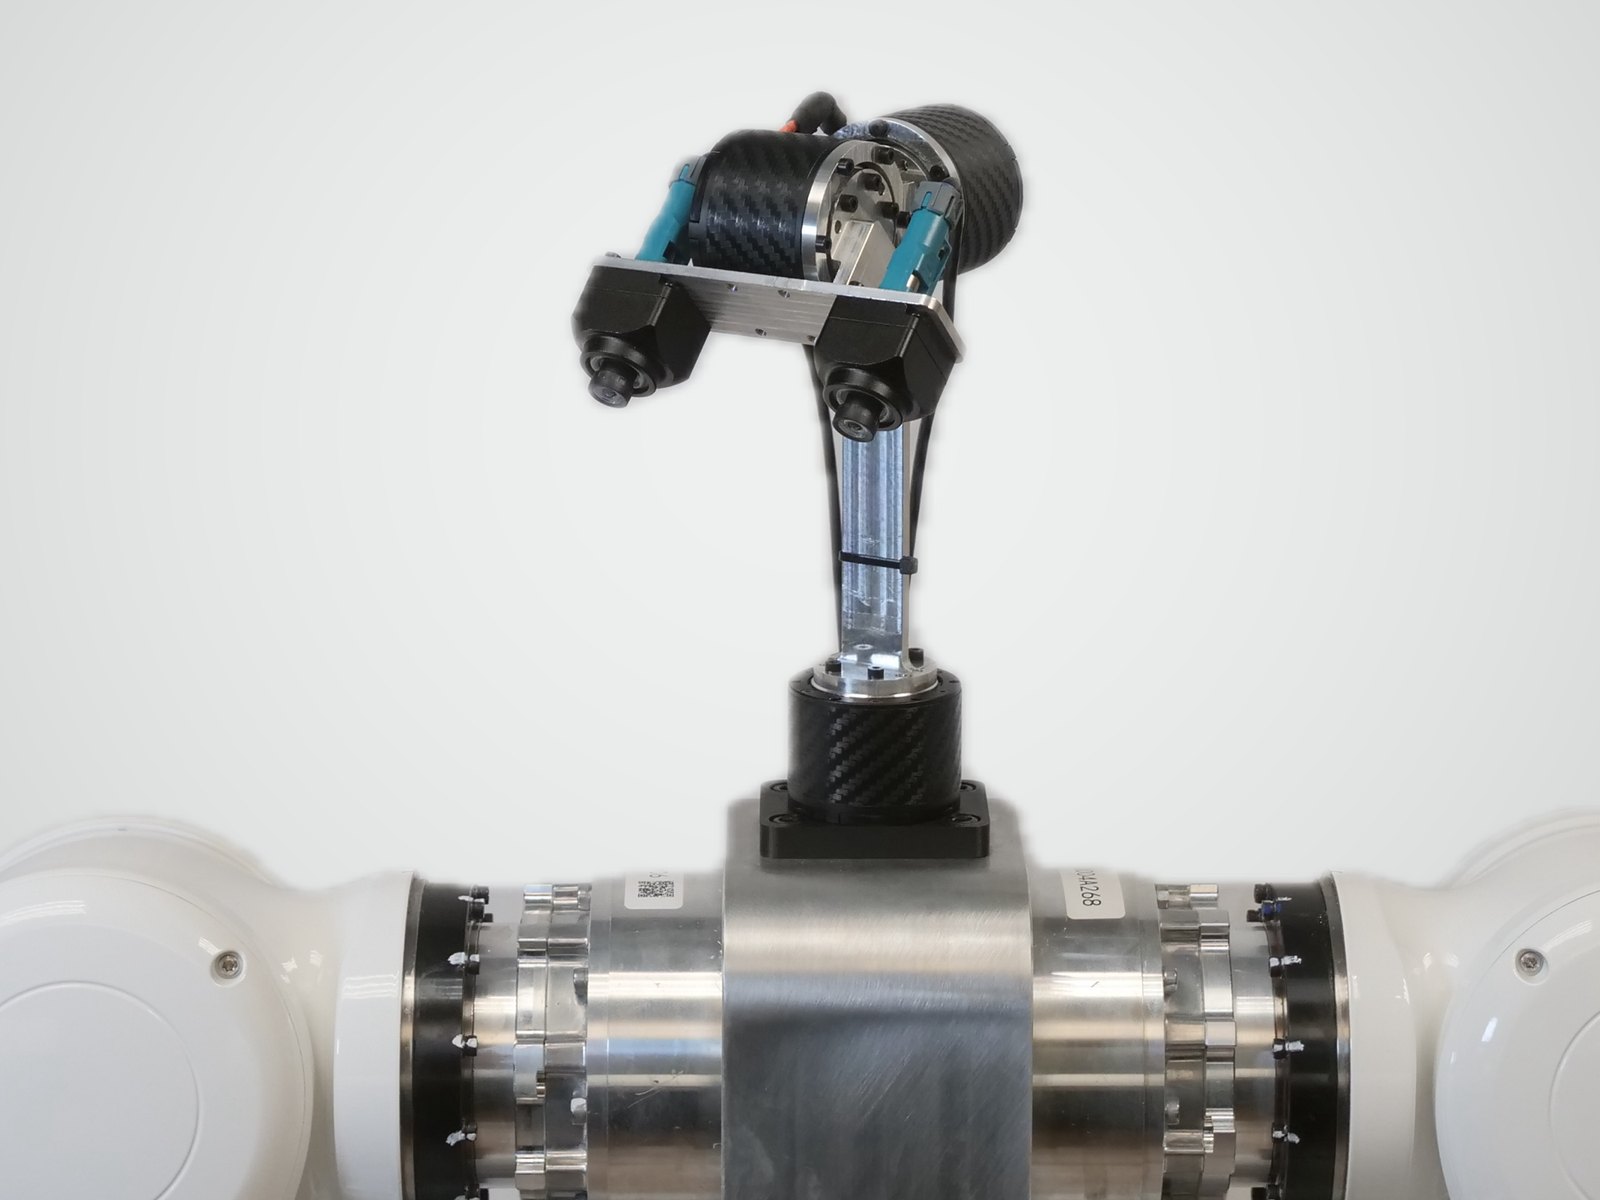
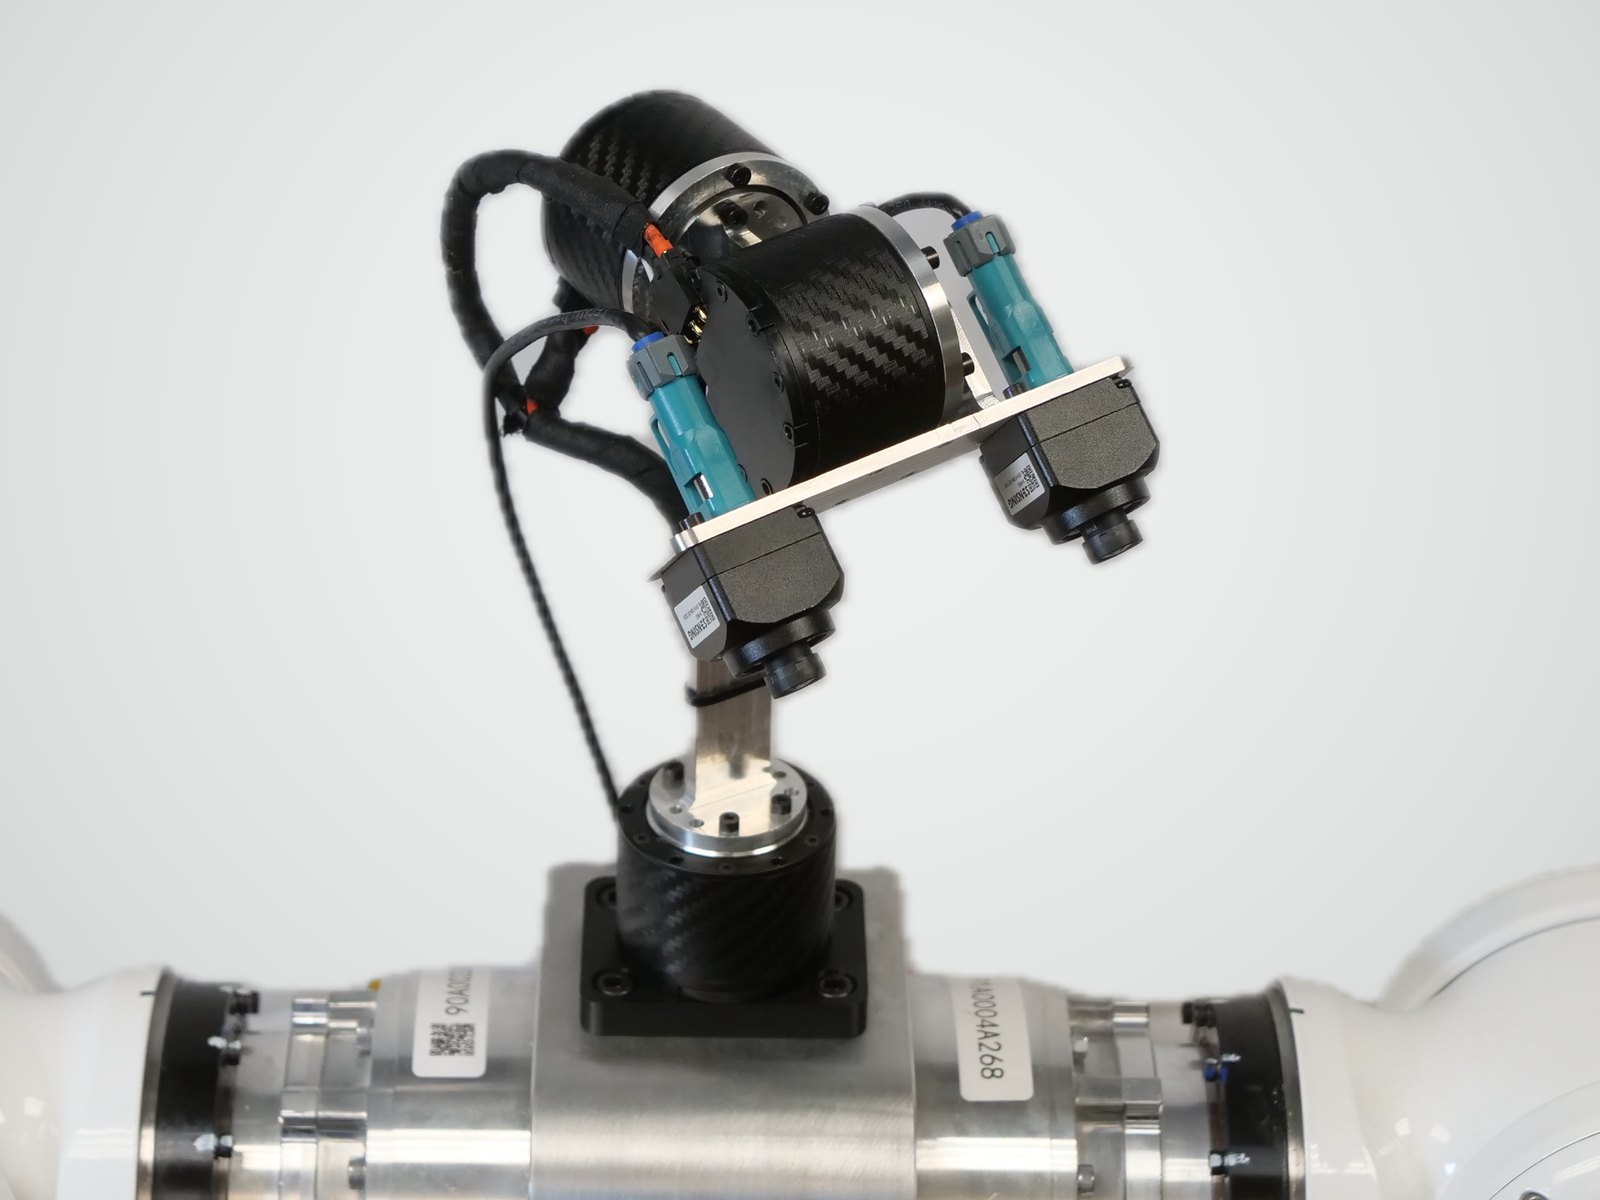
GEAR Neck photos and video. The neck turns, tilts and nods through yaw, roll and pitch.