Start Here
Overview
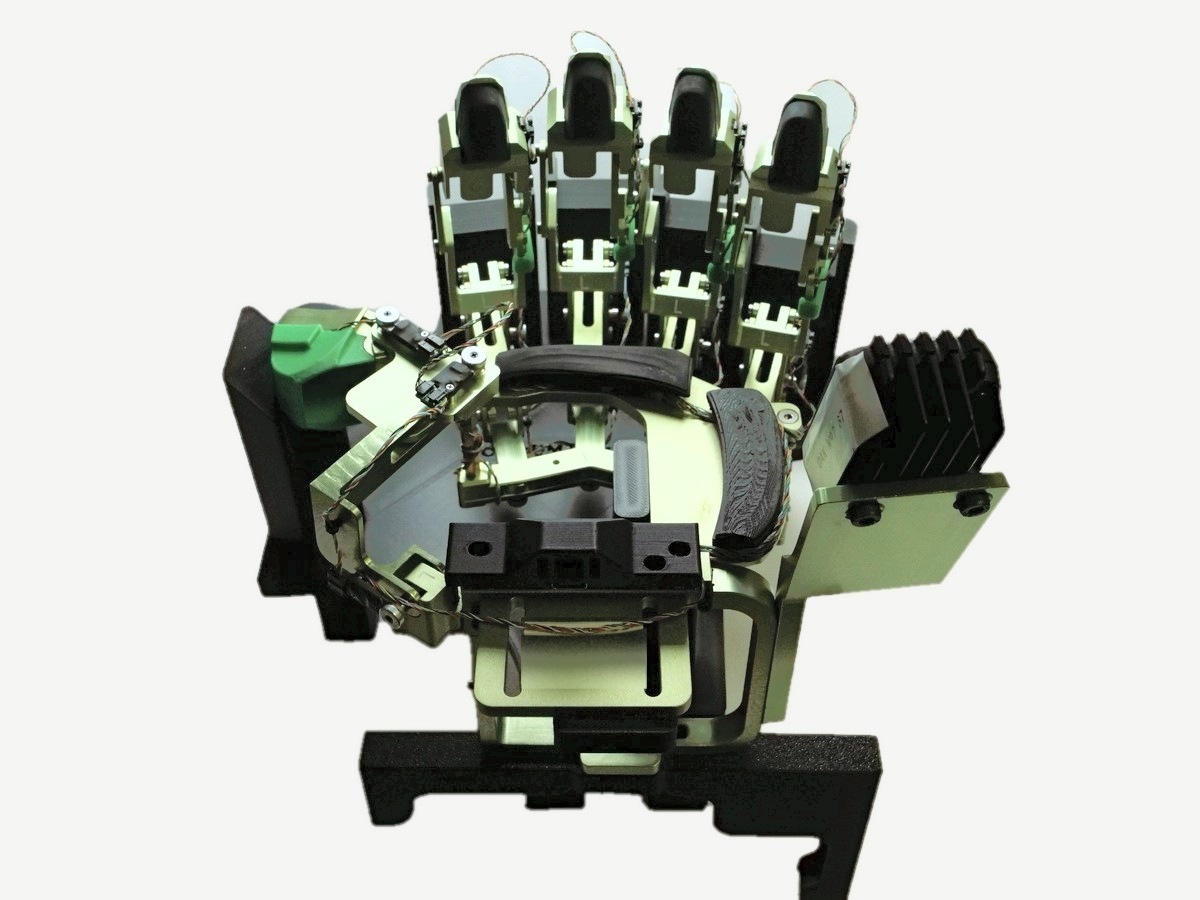
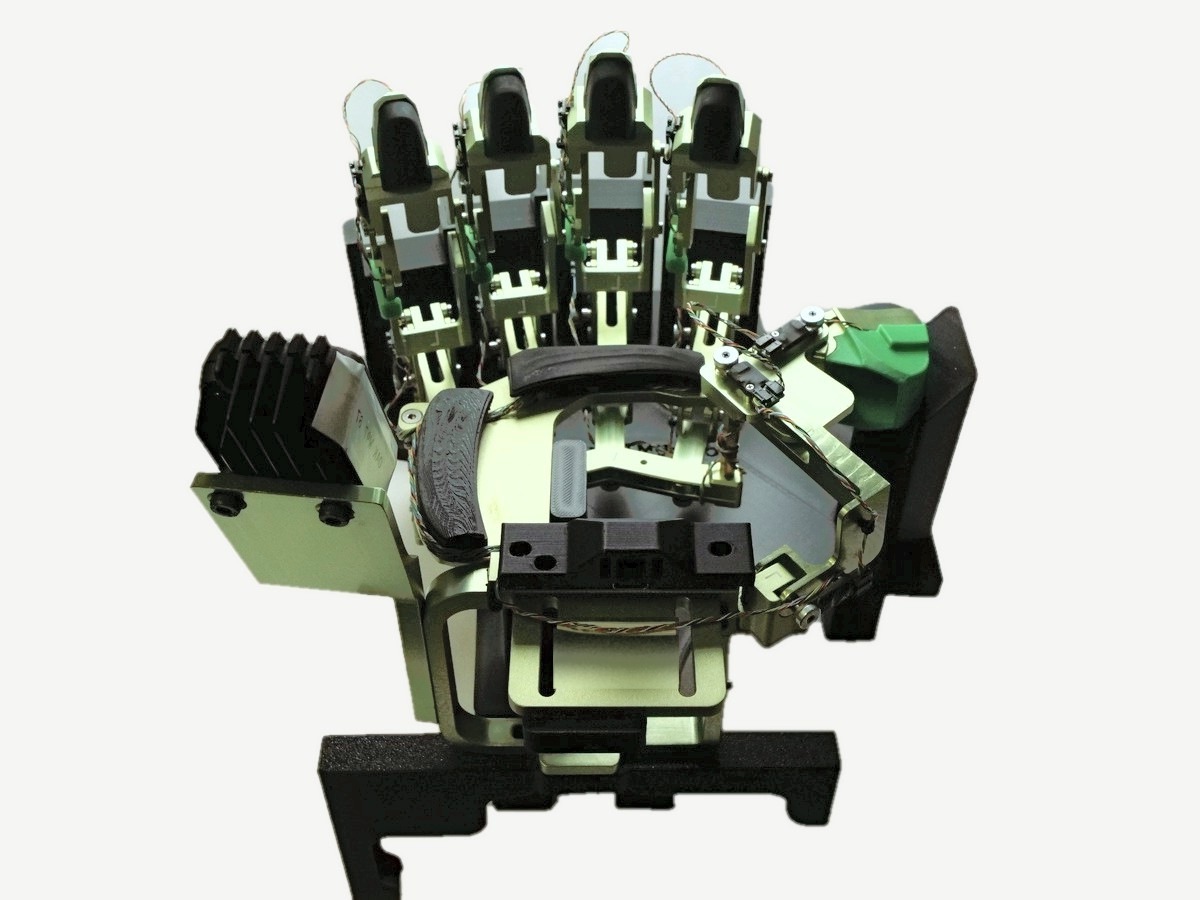
GEAR DexUMI is based on DexUMI (Xu et al., 2025): a wearable hand exoskeleton for recording dexterous human demonstrations, with no robot needed. Its finger linkages are designed around a dexterous robot hand, which narrows the gap between your hand’s motions and the robot’s, and because you touch objects through its fingertips, you feel each contact yourself. This build has more degrees of freedom and better wearability than the original DexUMI exoskeleton. Each hand reads its finger joints with 15 magnetic encoders, including knuckle abduction on all four fingers, senses normal and shear force at all five fingertips, and carries an OAK wrist camera. Worn on both hands, with an optional head camera, it records bimanual demonstrations. The data trains dexterous manipulation policies and robot foundation models; we fully tested the design by collecting data for GR00T 2. It is for teams who want dexterous training data without teleoperating a robot.
License
The DexUMI data-collection software and the hand monitor use Apache-2.0 by default. The complete Record3D-derived iPhone adapter, including NVIDIA adaptations, is LGPL-2.1-only. The X Hand URDFs are the vendor's, under the MIT License. Other third-party components keep their own licenses; see NOTICE. The hardware designs and this documentation are licensed under CC BY 4.0, except vendor product photos. See the repository licensing section.